
04/2026 - PresentAMR Sterilization Robot
Agilmatic Electric Ltd, (Agilbot Project | backed by Accelerator Centre)
Project Details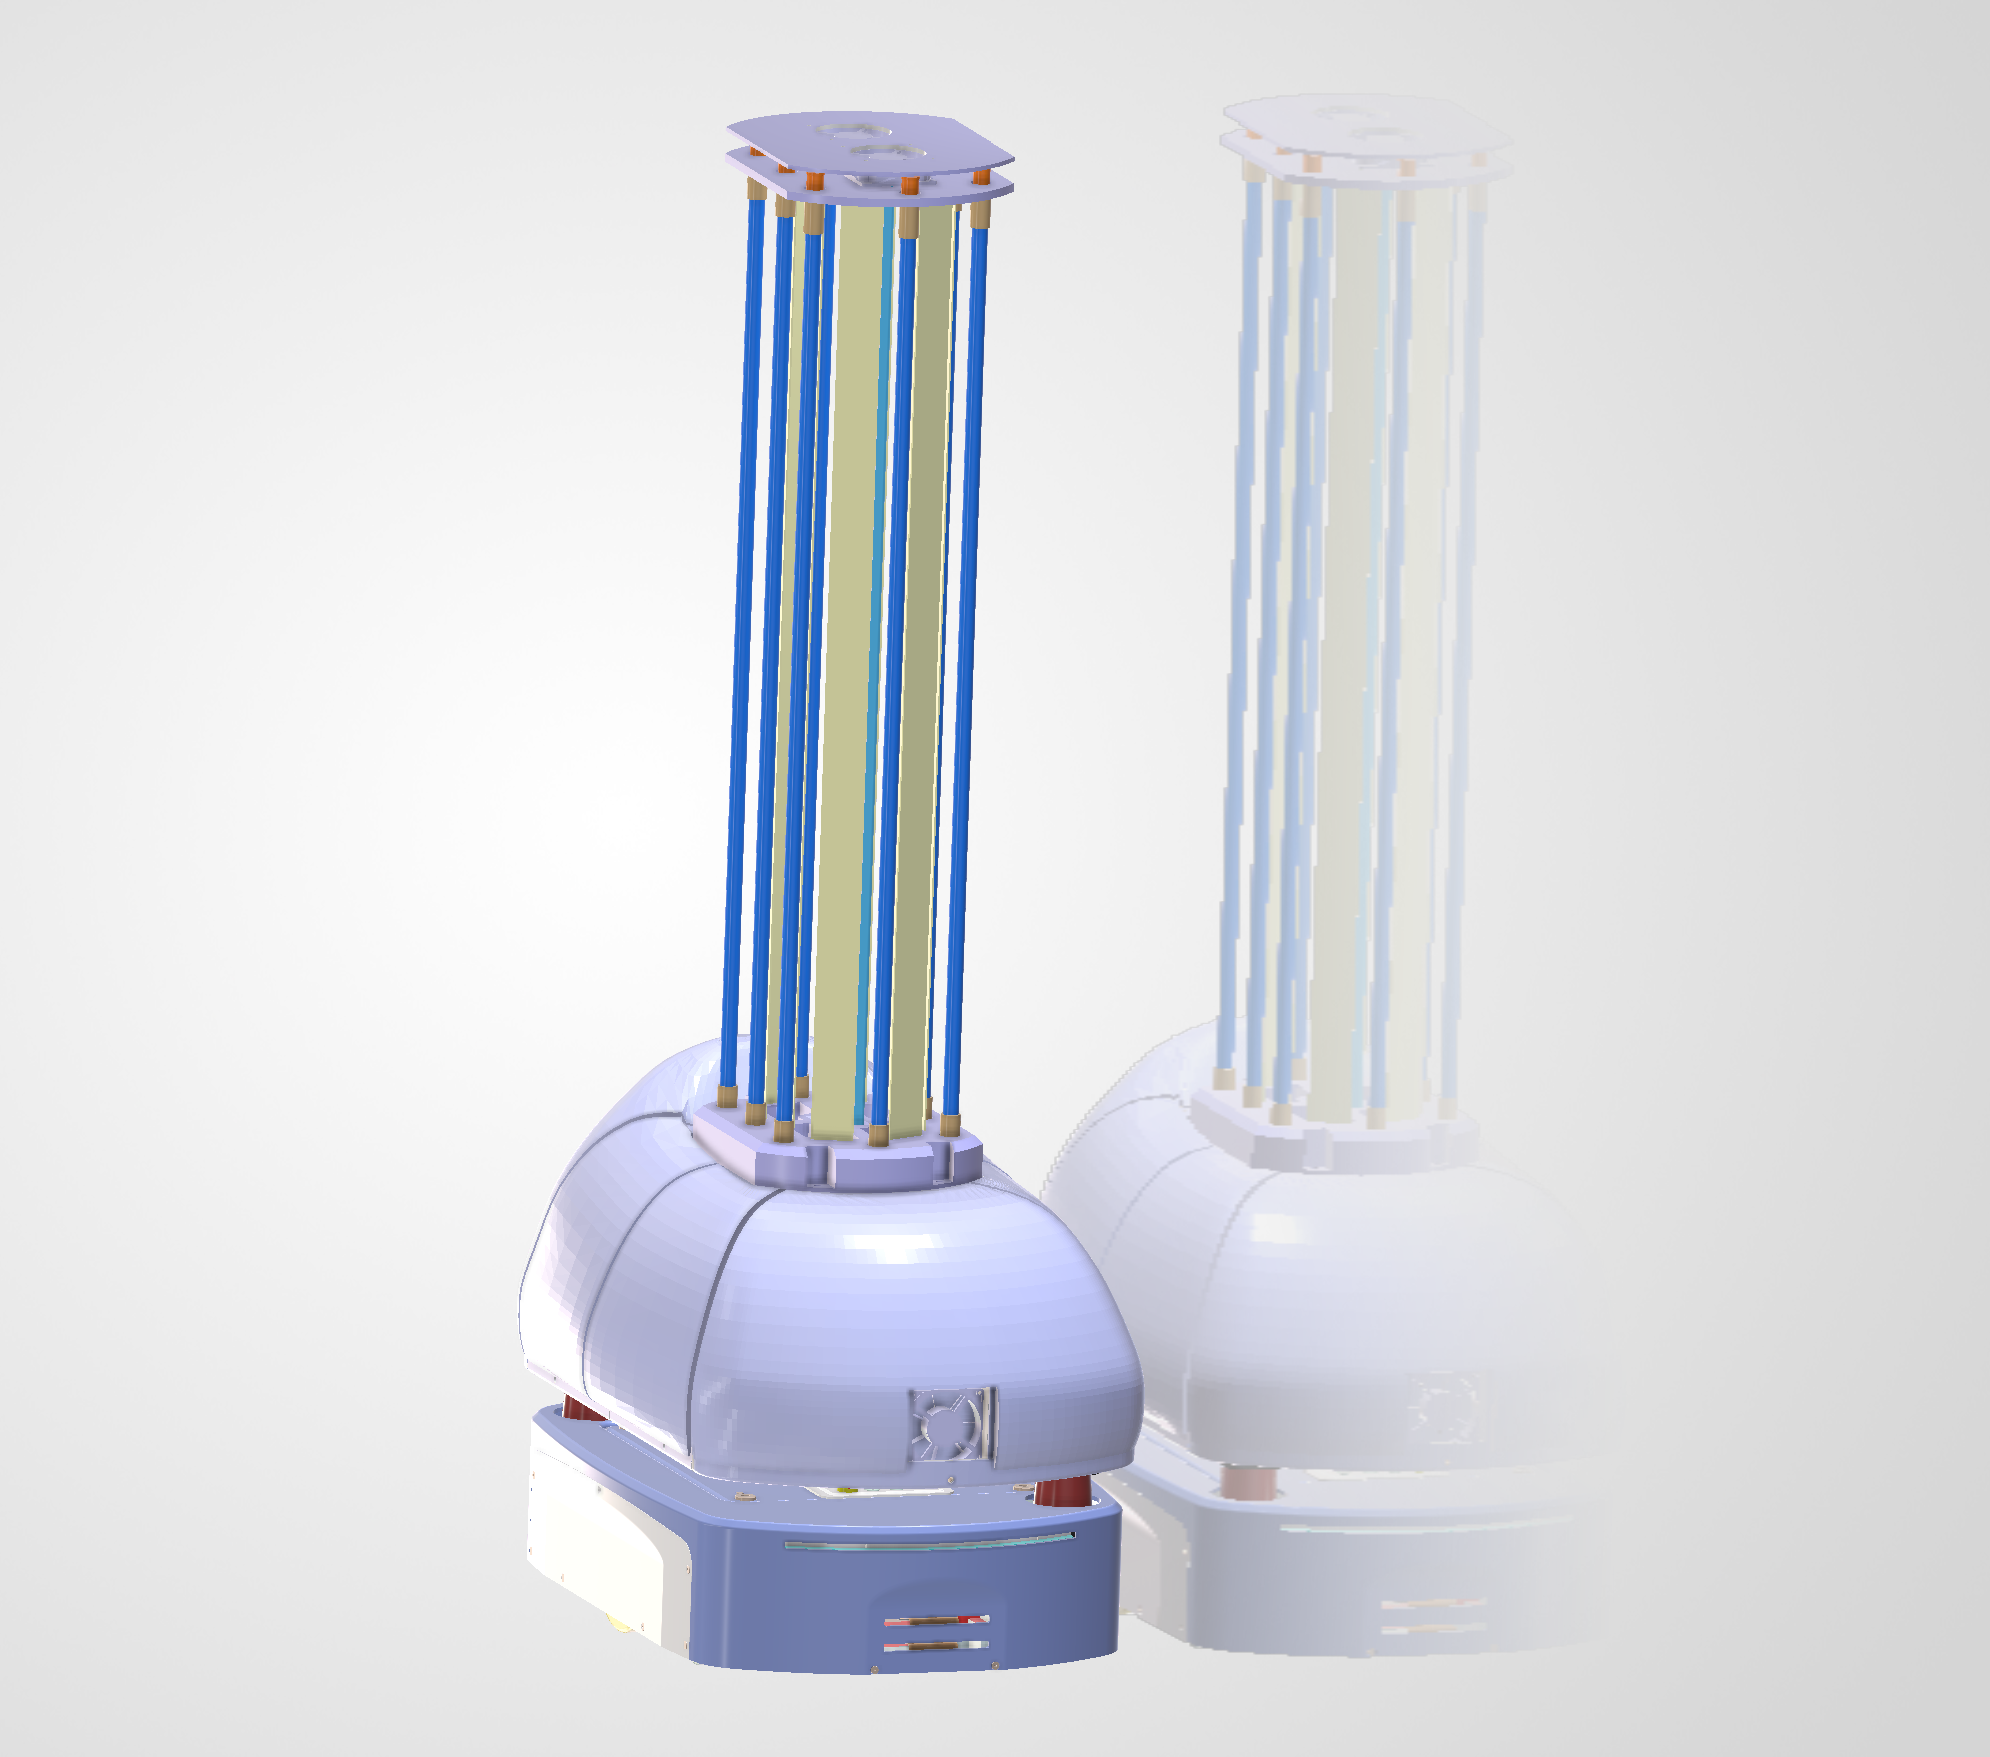
Developing autonomous mobile sterilization robot that delivers UVC dosages to targeted surface areas and air volumes. The system performs human-free environmental patrols to safely neutralize surface and airborne pathogens without manual intervention.
❋ Mechanical DesignEngineering and modelled functional robotic chassis, housings, and internal mechanisms using SolidWorks
❋ Hardware ValidationDesigned and executed physical testing protocols to verify electromechanical reliability and operational safety.
❋ Systems IntegrationUnified mechanical assemblies, 48V electrical systems, and embedded computing platforms into functional prototypes
*All shown information has been already approved by my supervisor
❋ Project ManagementDefined product requirements, tracked budgets, and generated BOMS to create a cost-optimized product
Agilbot R&D Process
Research
Agilmatic focuses on developing AMRs for various purposes, and I was tasked to look within the healthcare industry. I conducted research into sterilization robots, where I looked at the market, competitors, and various methods of sterilization/disinfection (research summary below). From this research the Agilbot concept came to be, which was called INNO in the beginning.
Summary
Initial Design Proposal
From my research, I created a short design proposal pitch for approval of creating a proof of concept prototype and continuing on project. For this pitch, an initial CAD was created for the robot, for visual purposes.

More Details


V1.1 Design and Proof of Concept
After approval, I worked on designing a proof of concept prototype. I have full ownership of this project, where I was in charge of defining the specs of the entire robot and the mechanical design of the lamp module
Mechanical Design
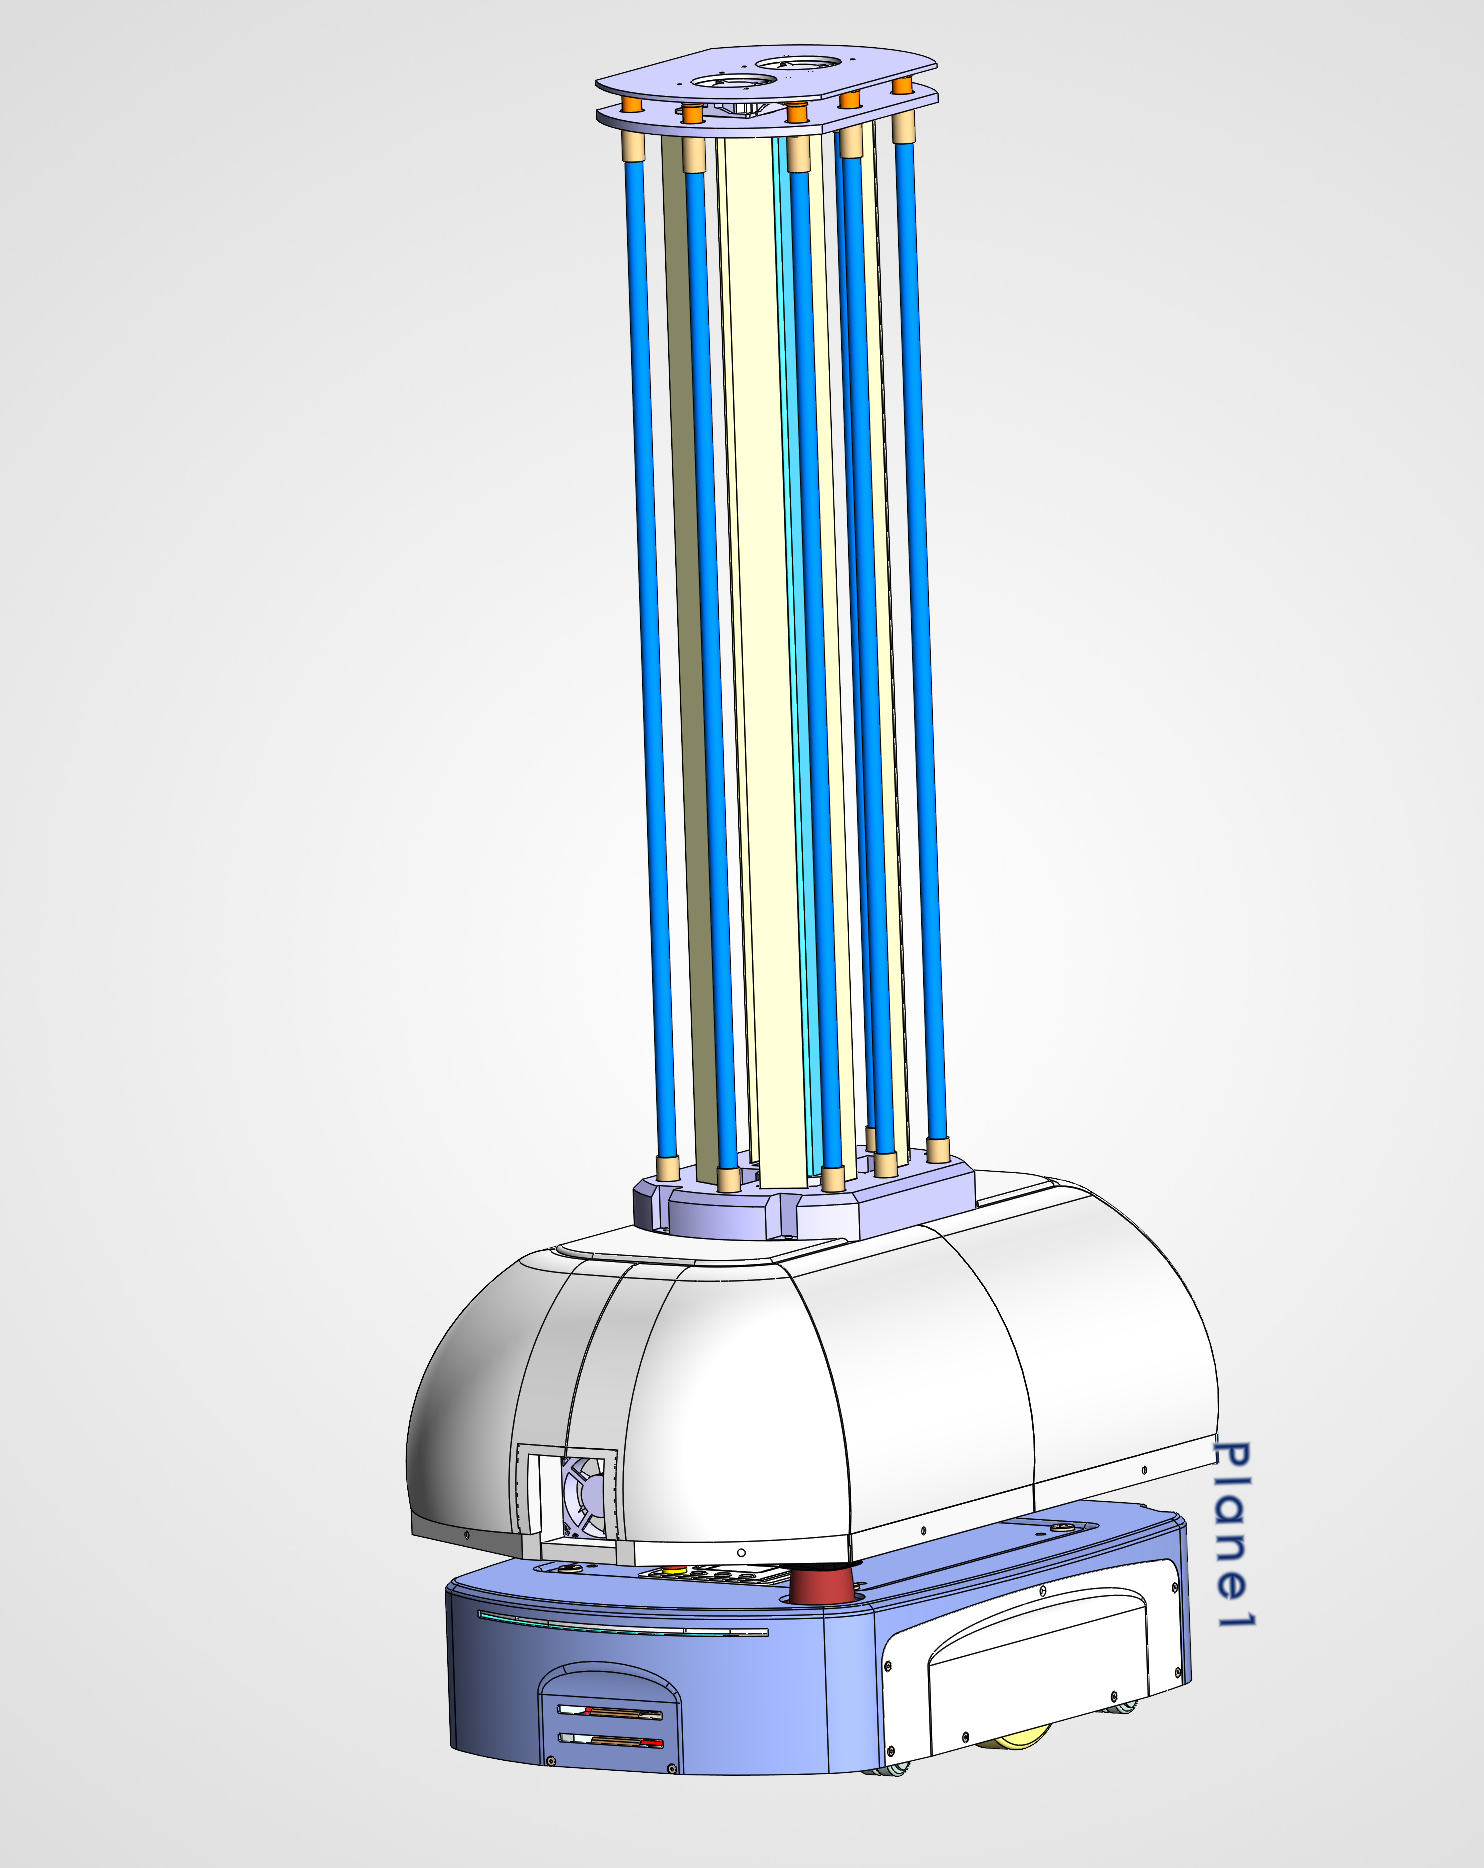
Full CAD of Prototype
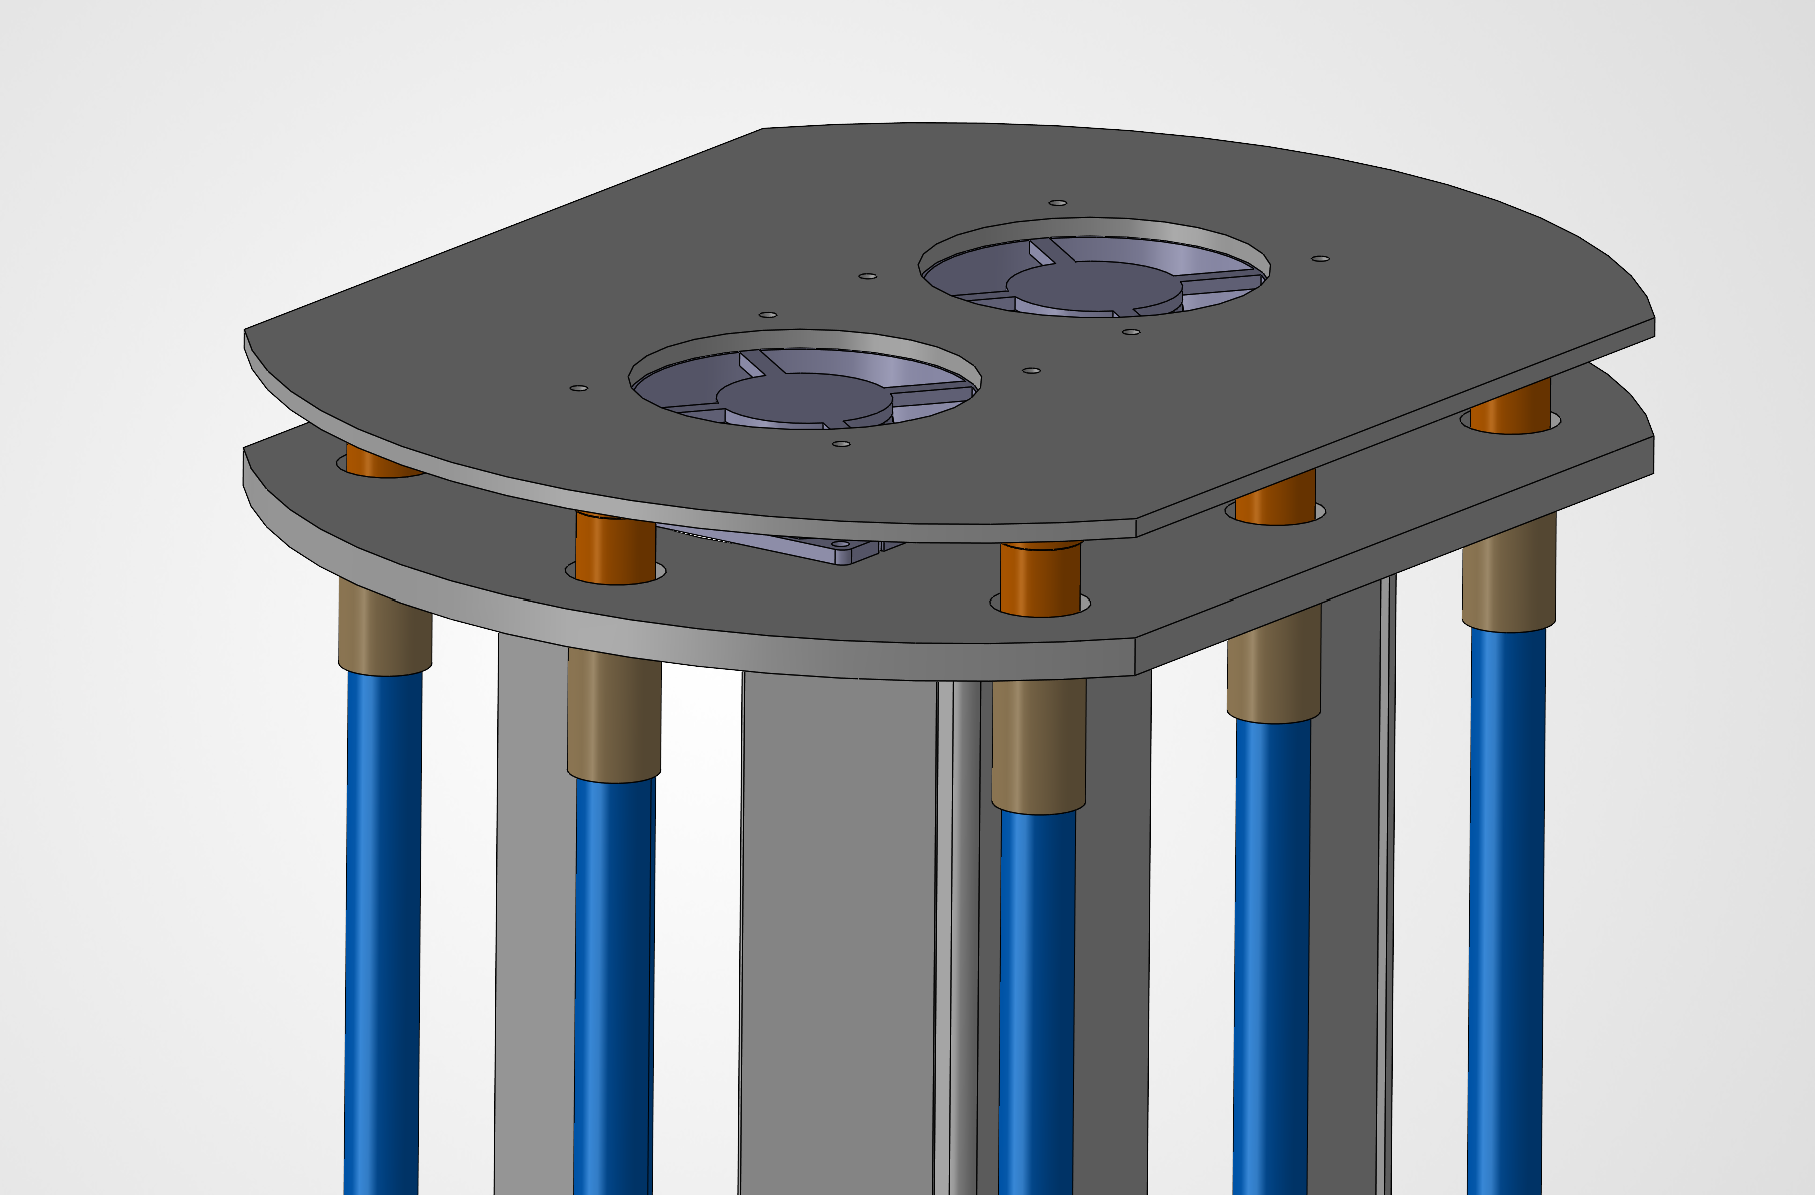
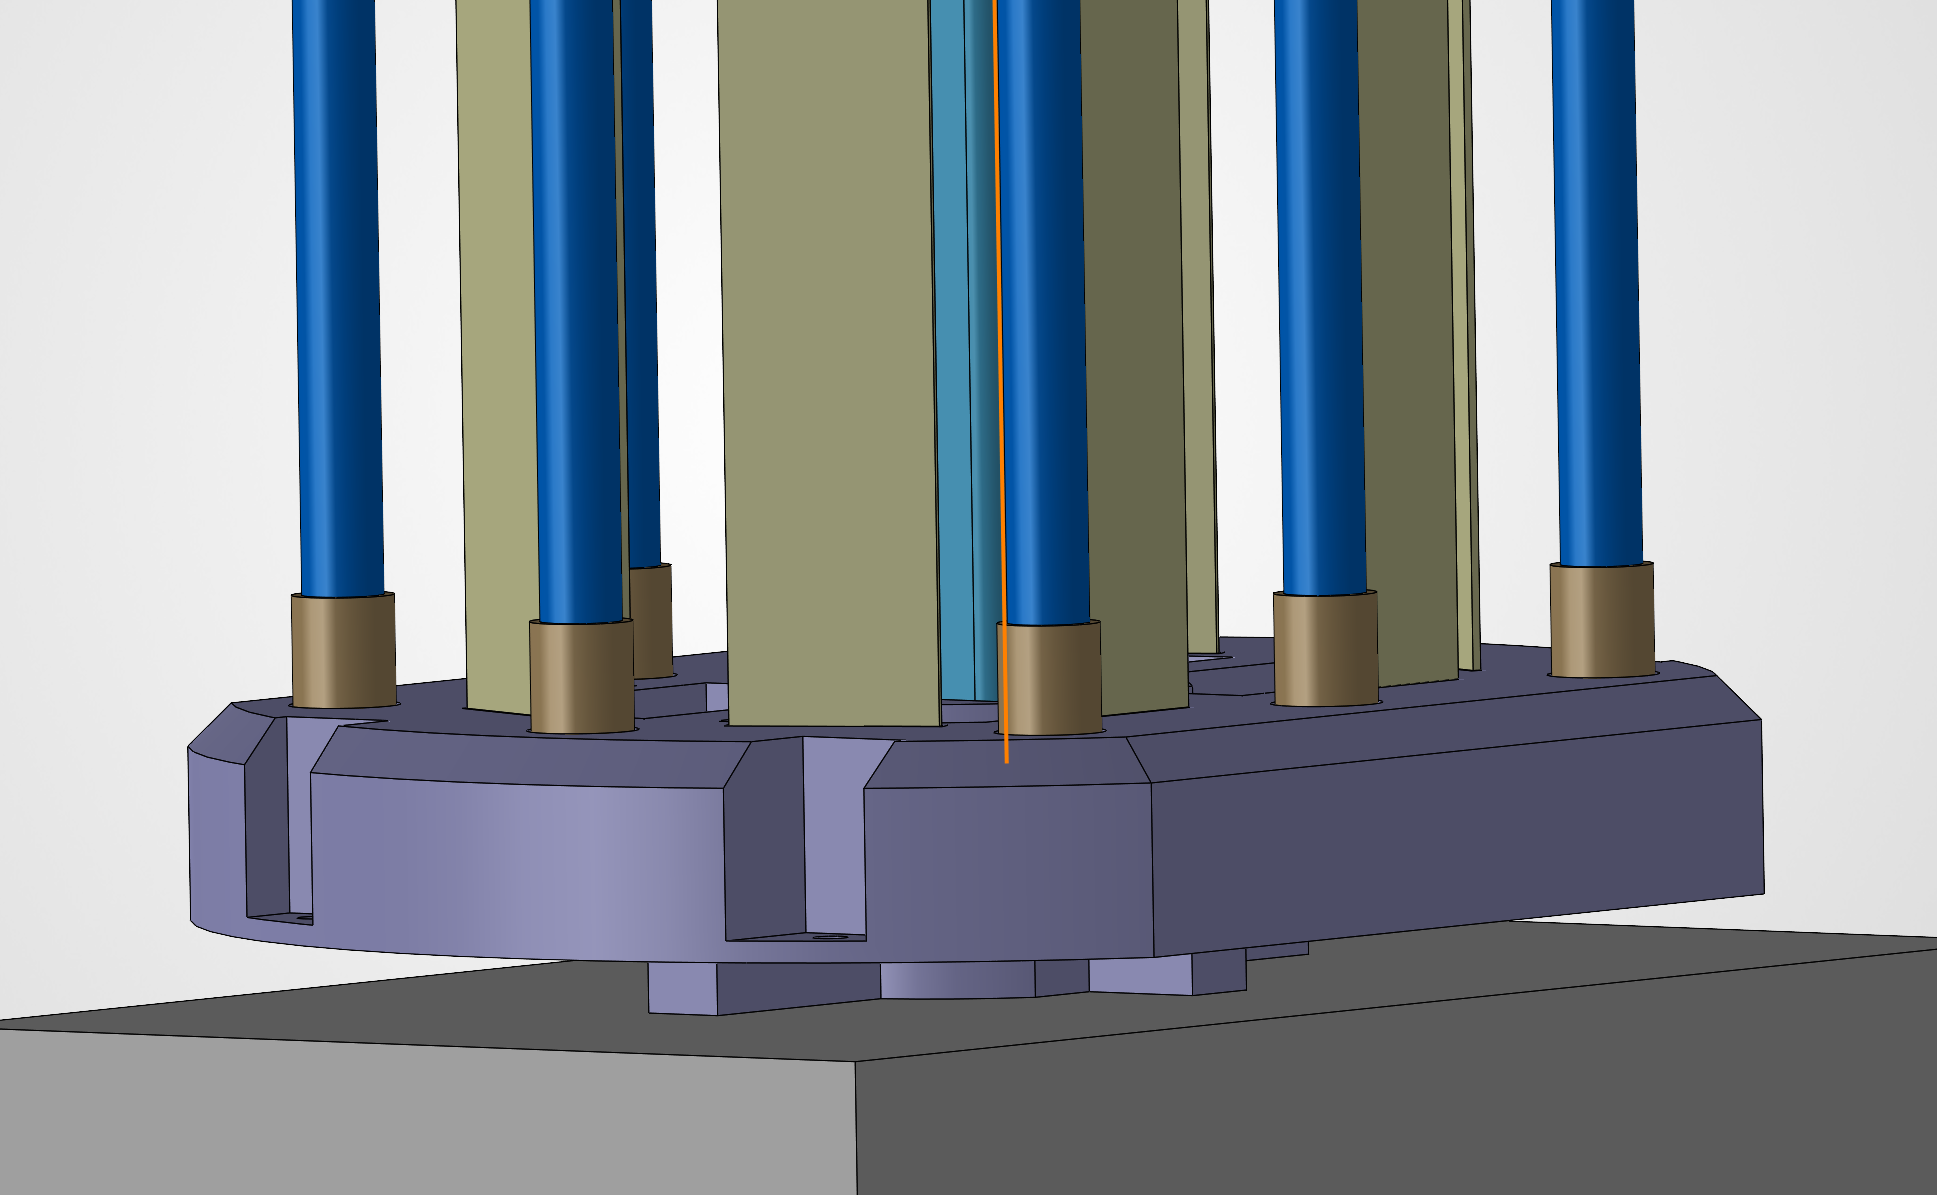
Prototyping
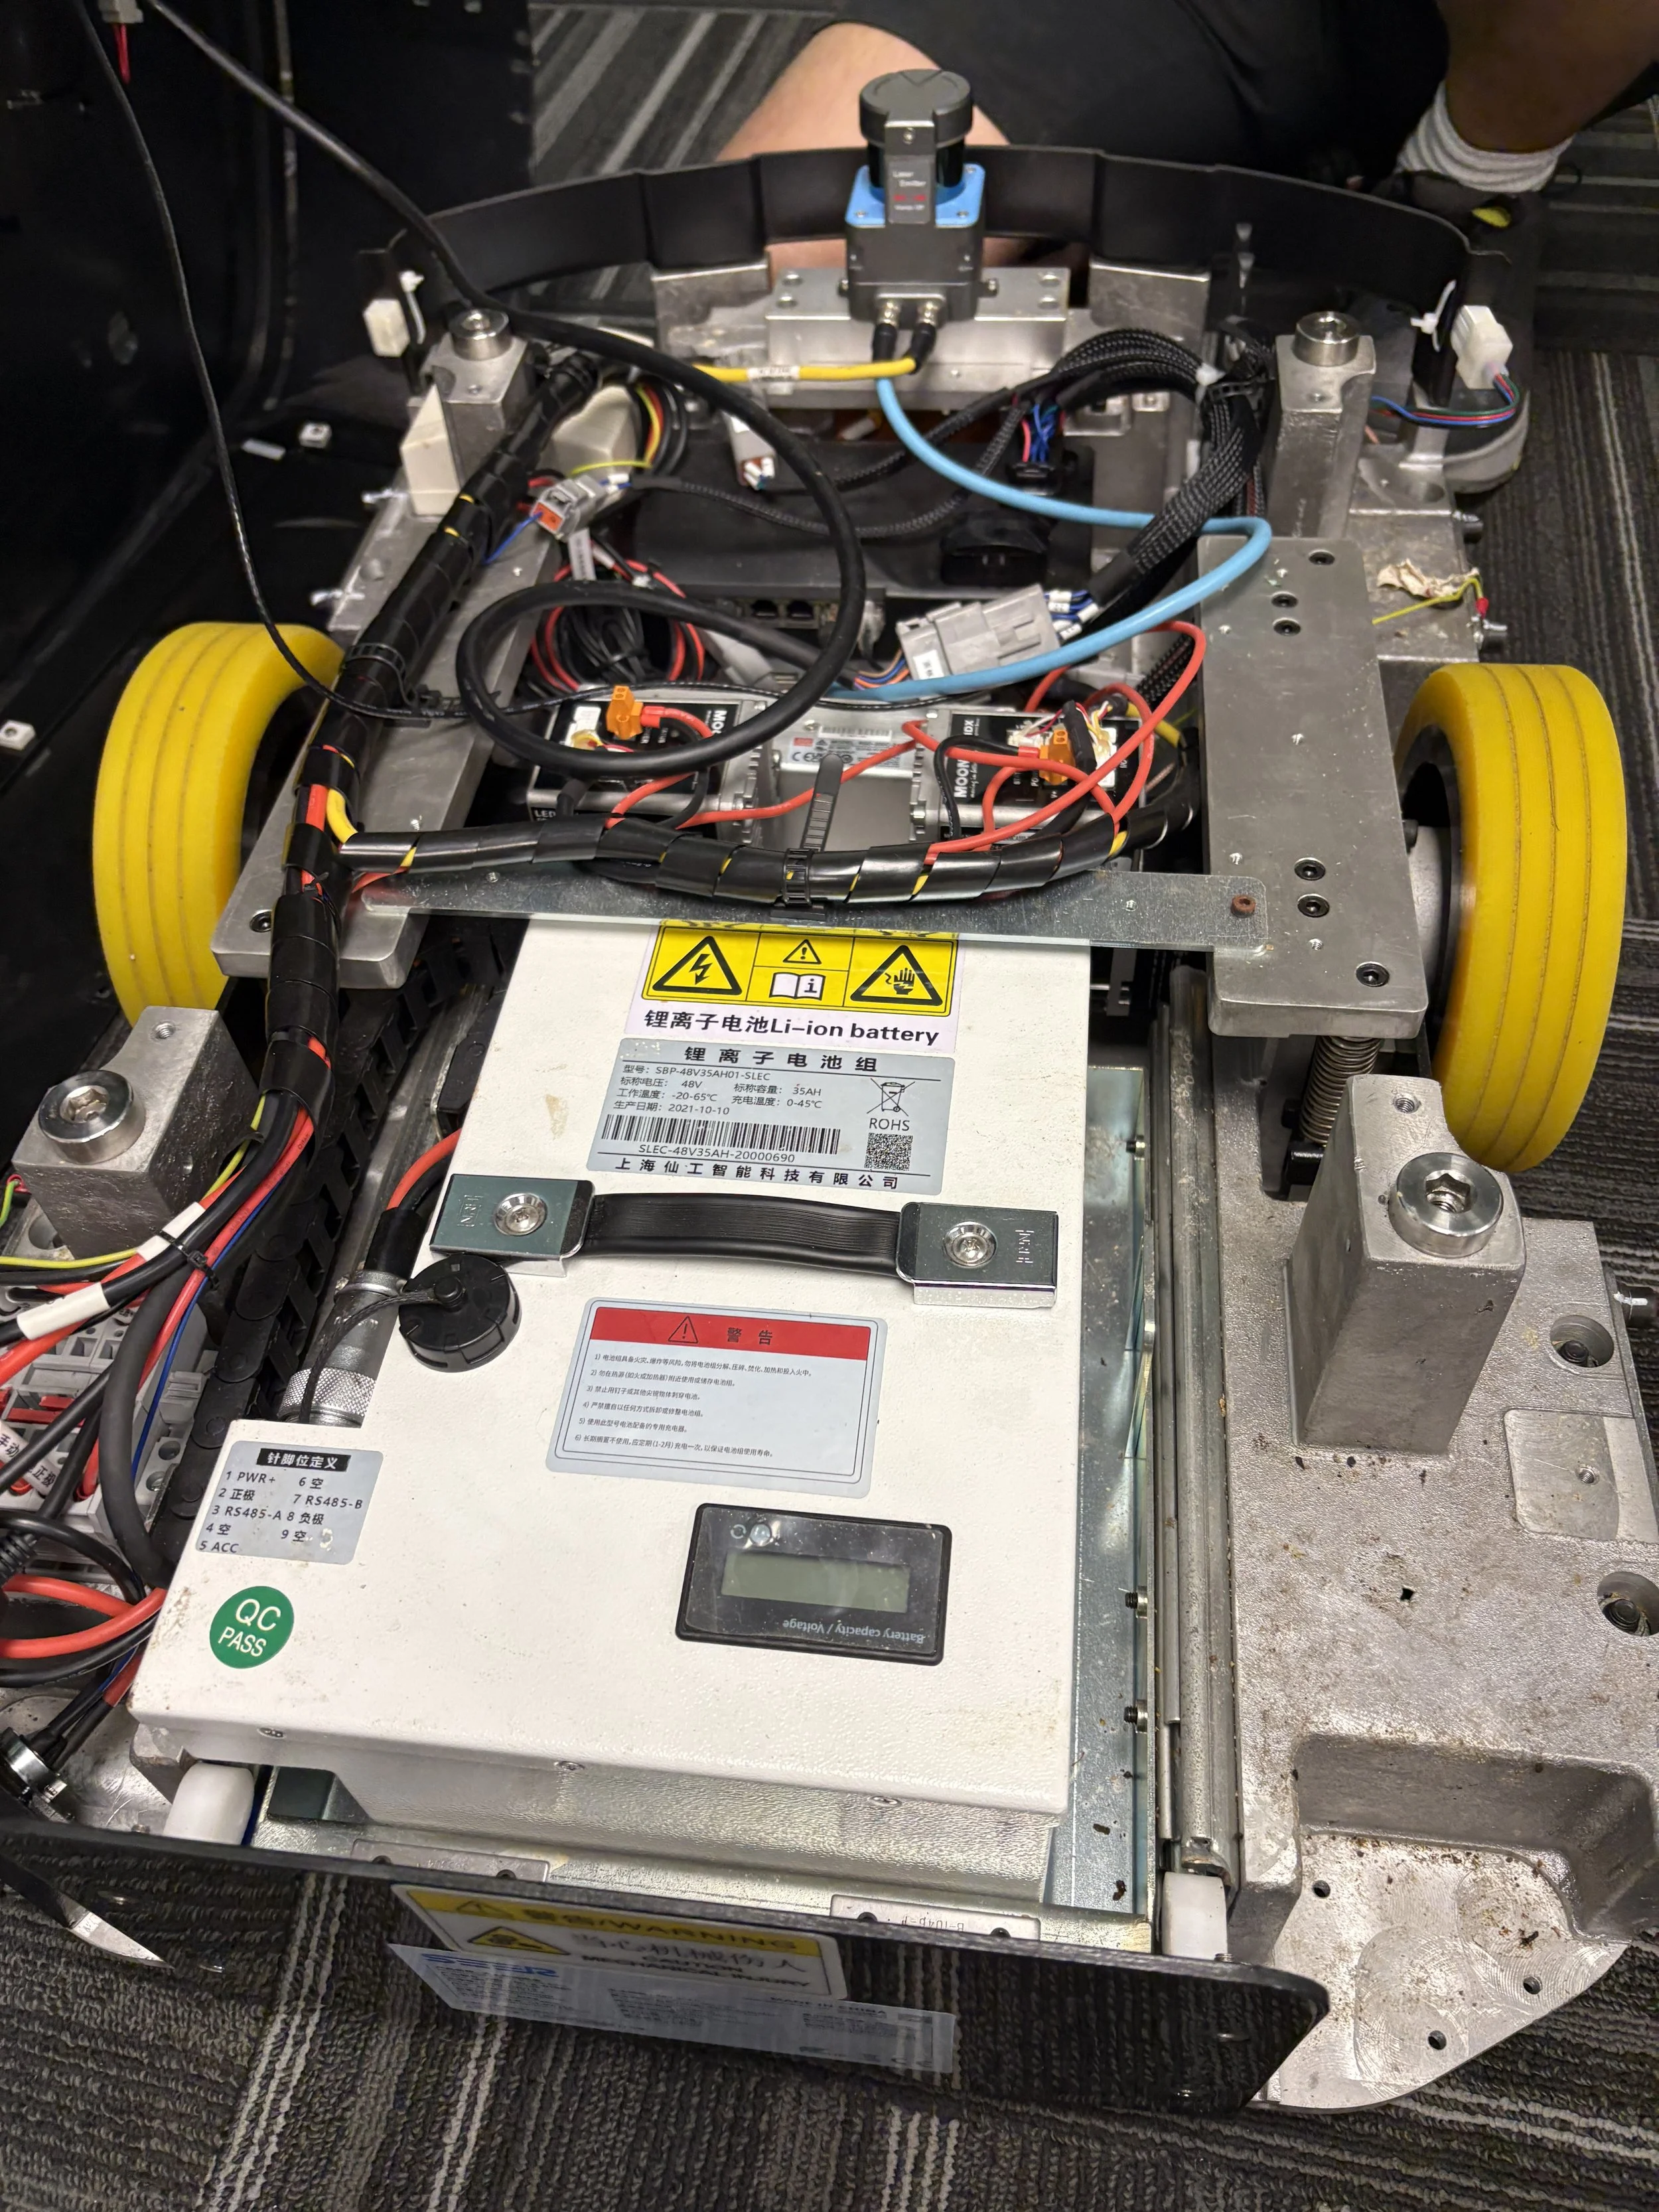
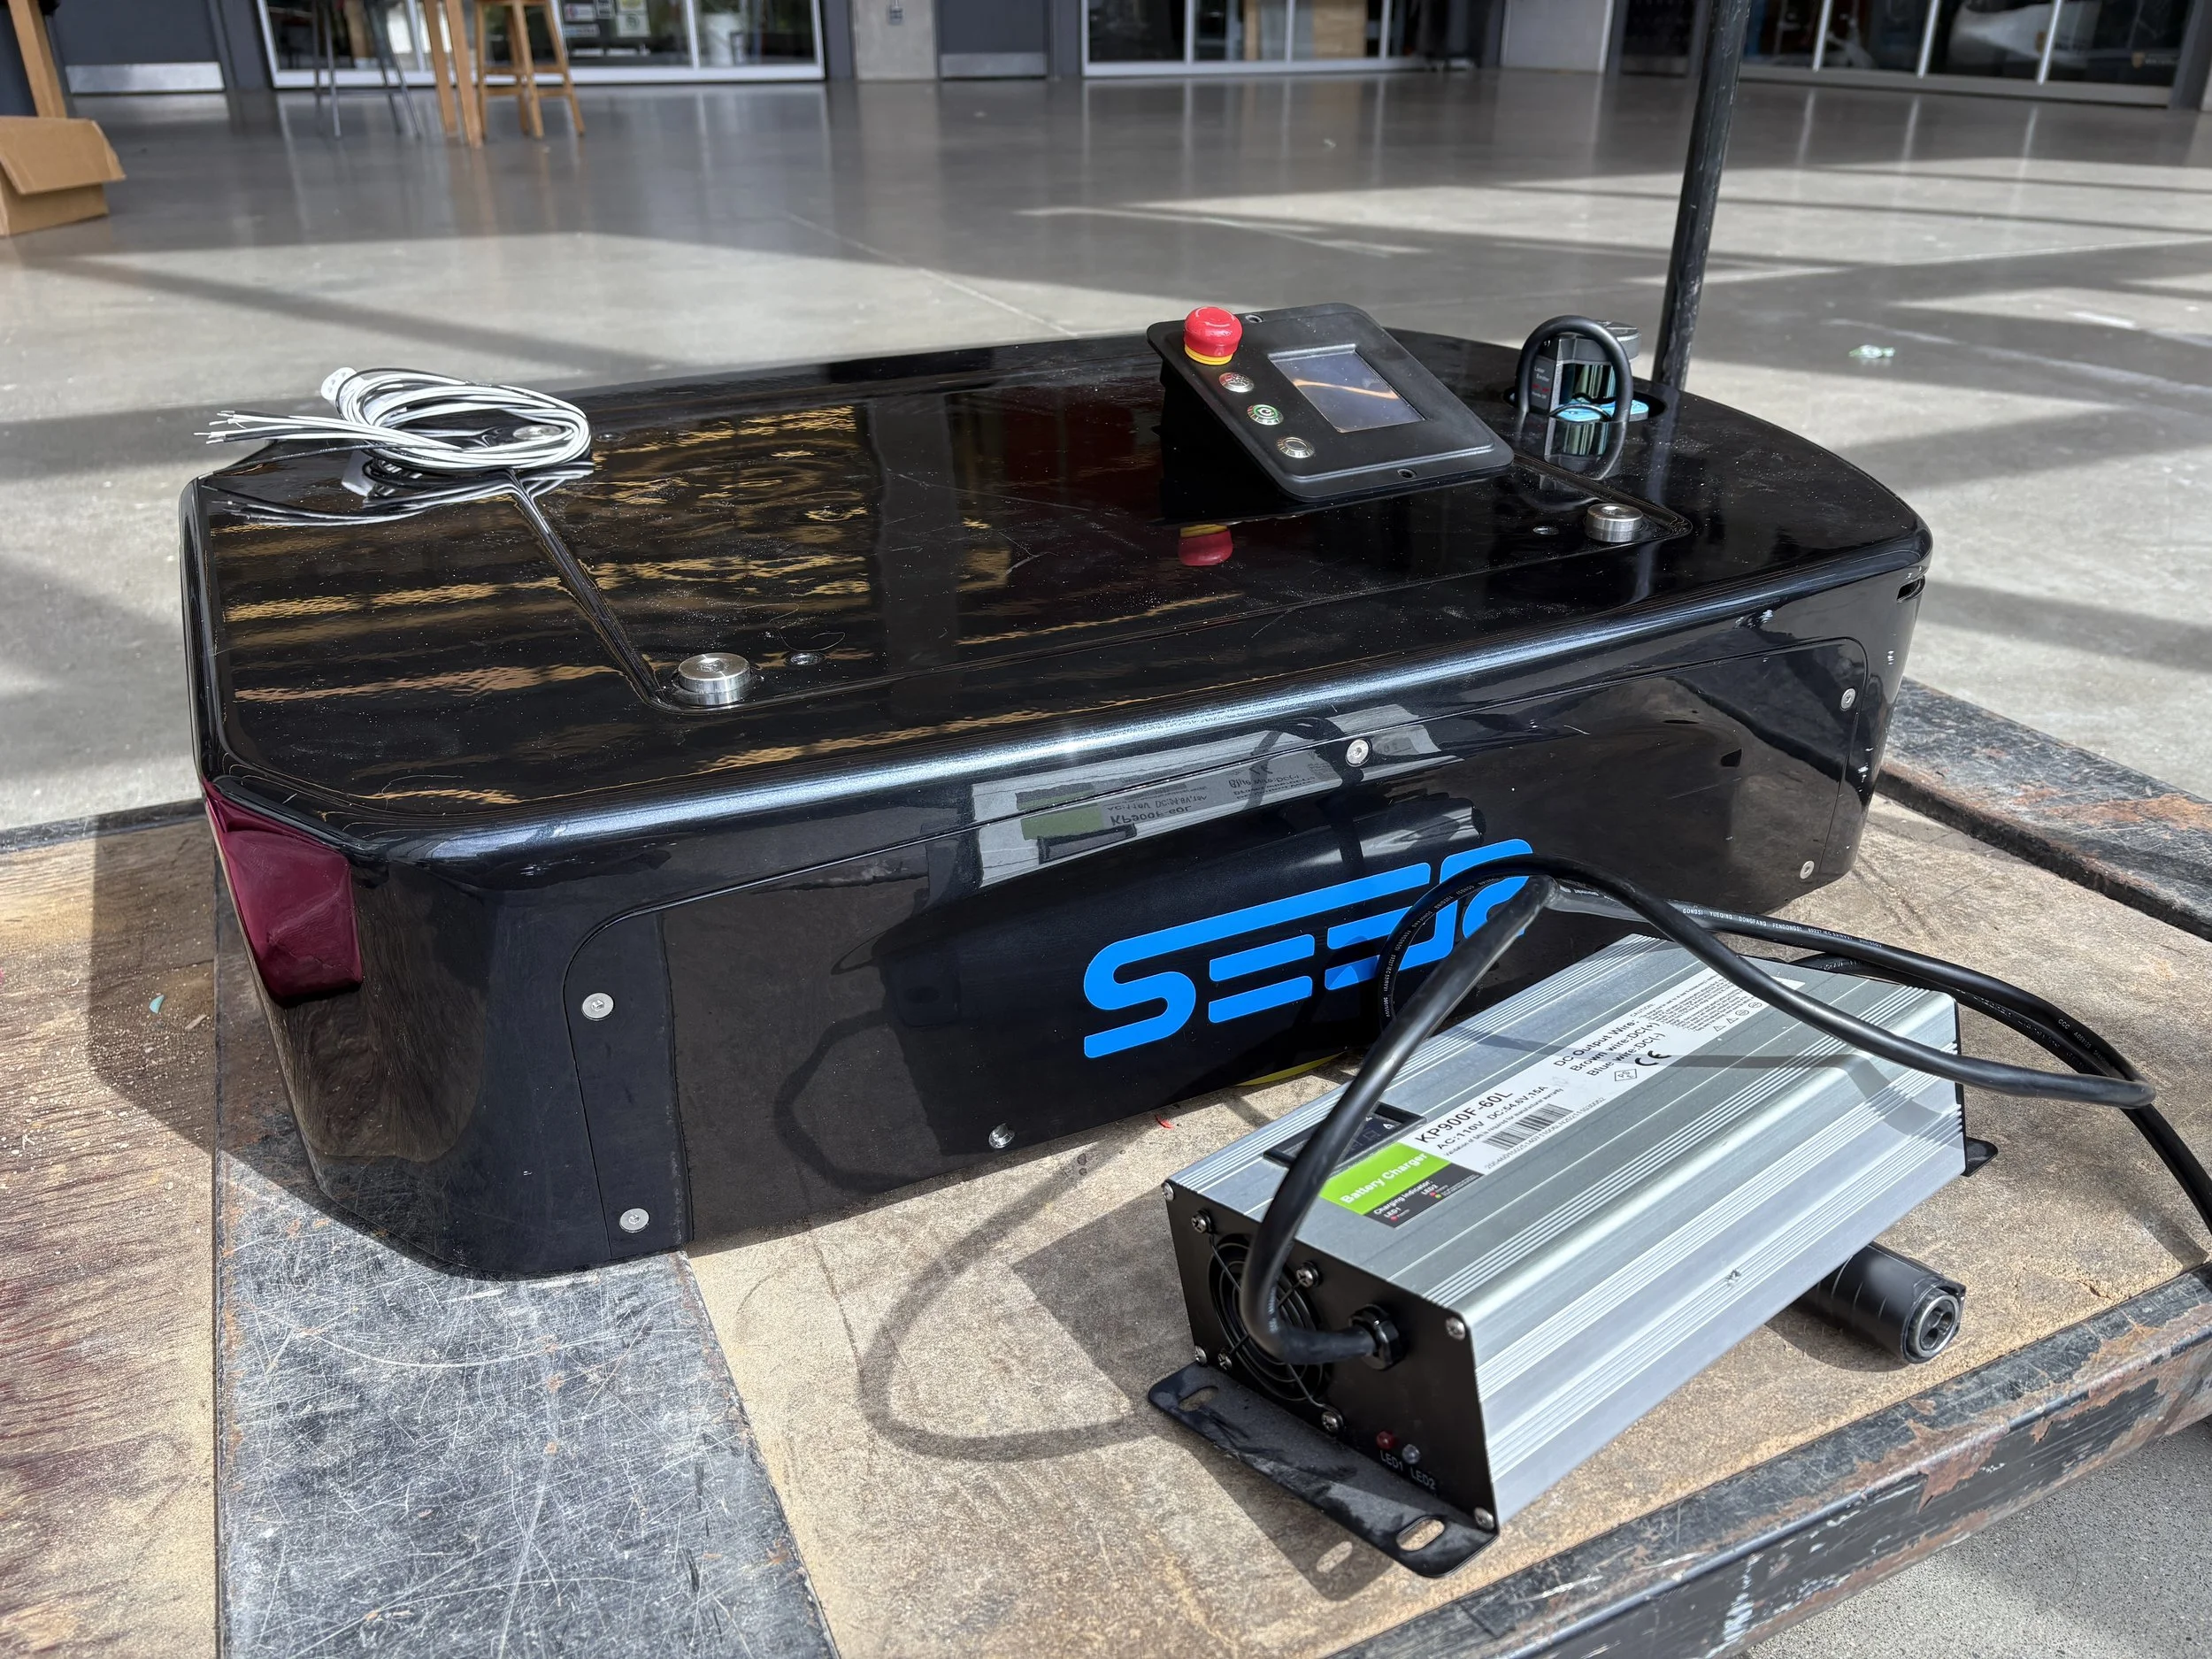
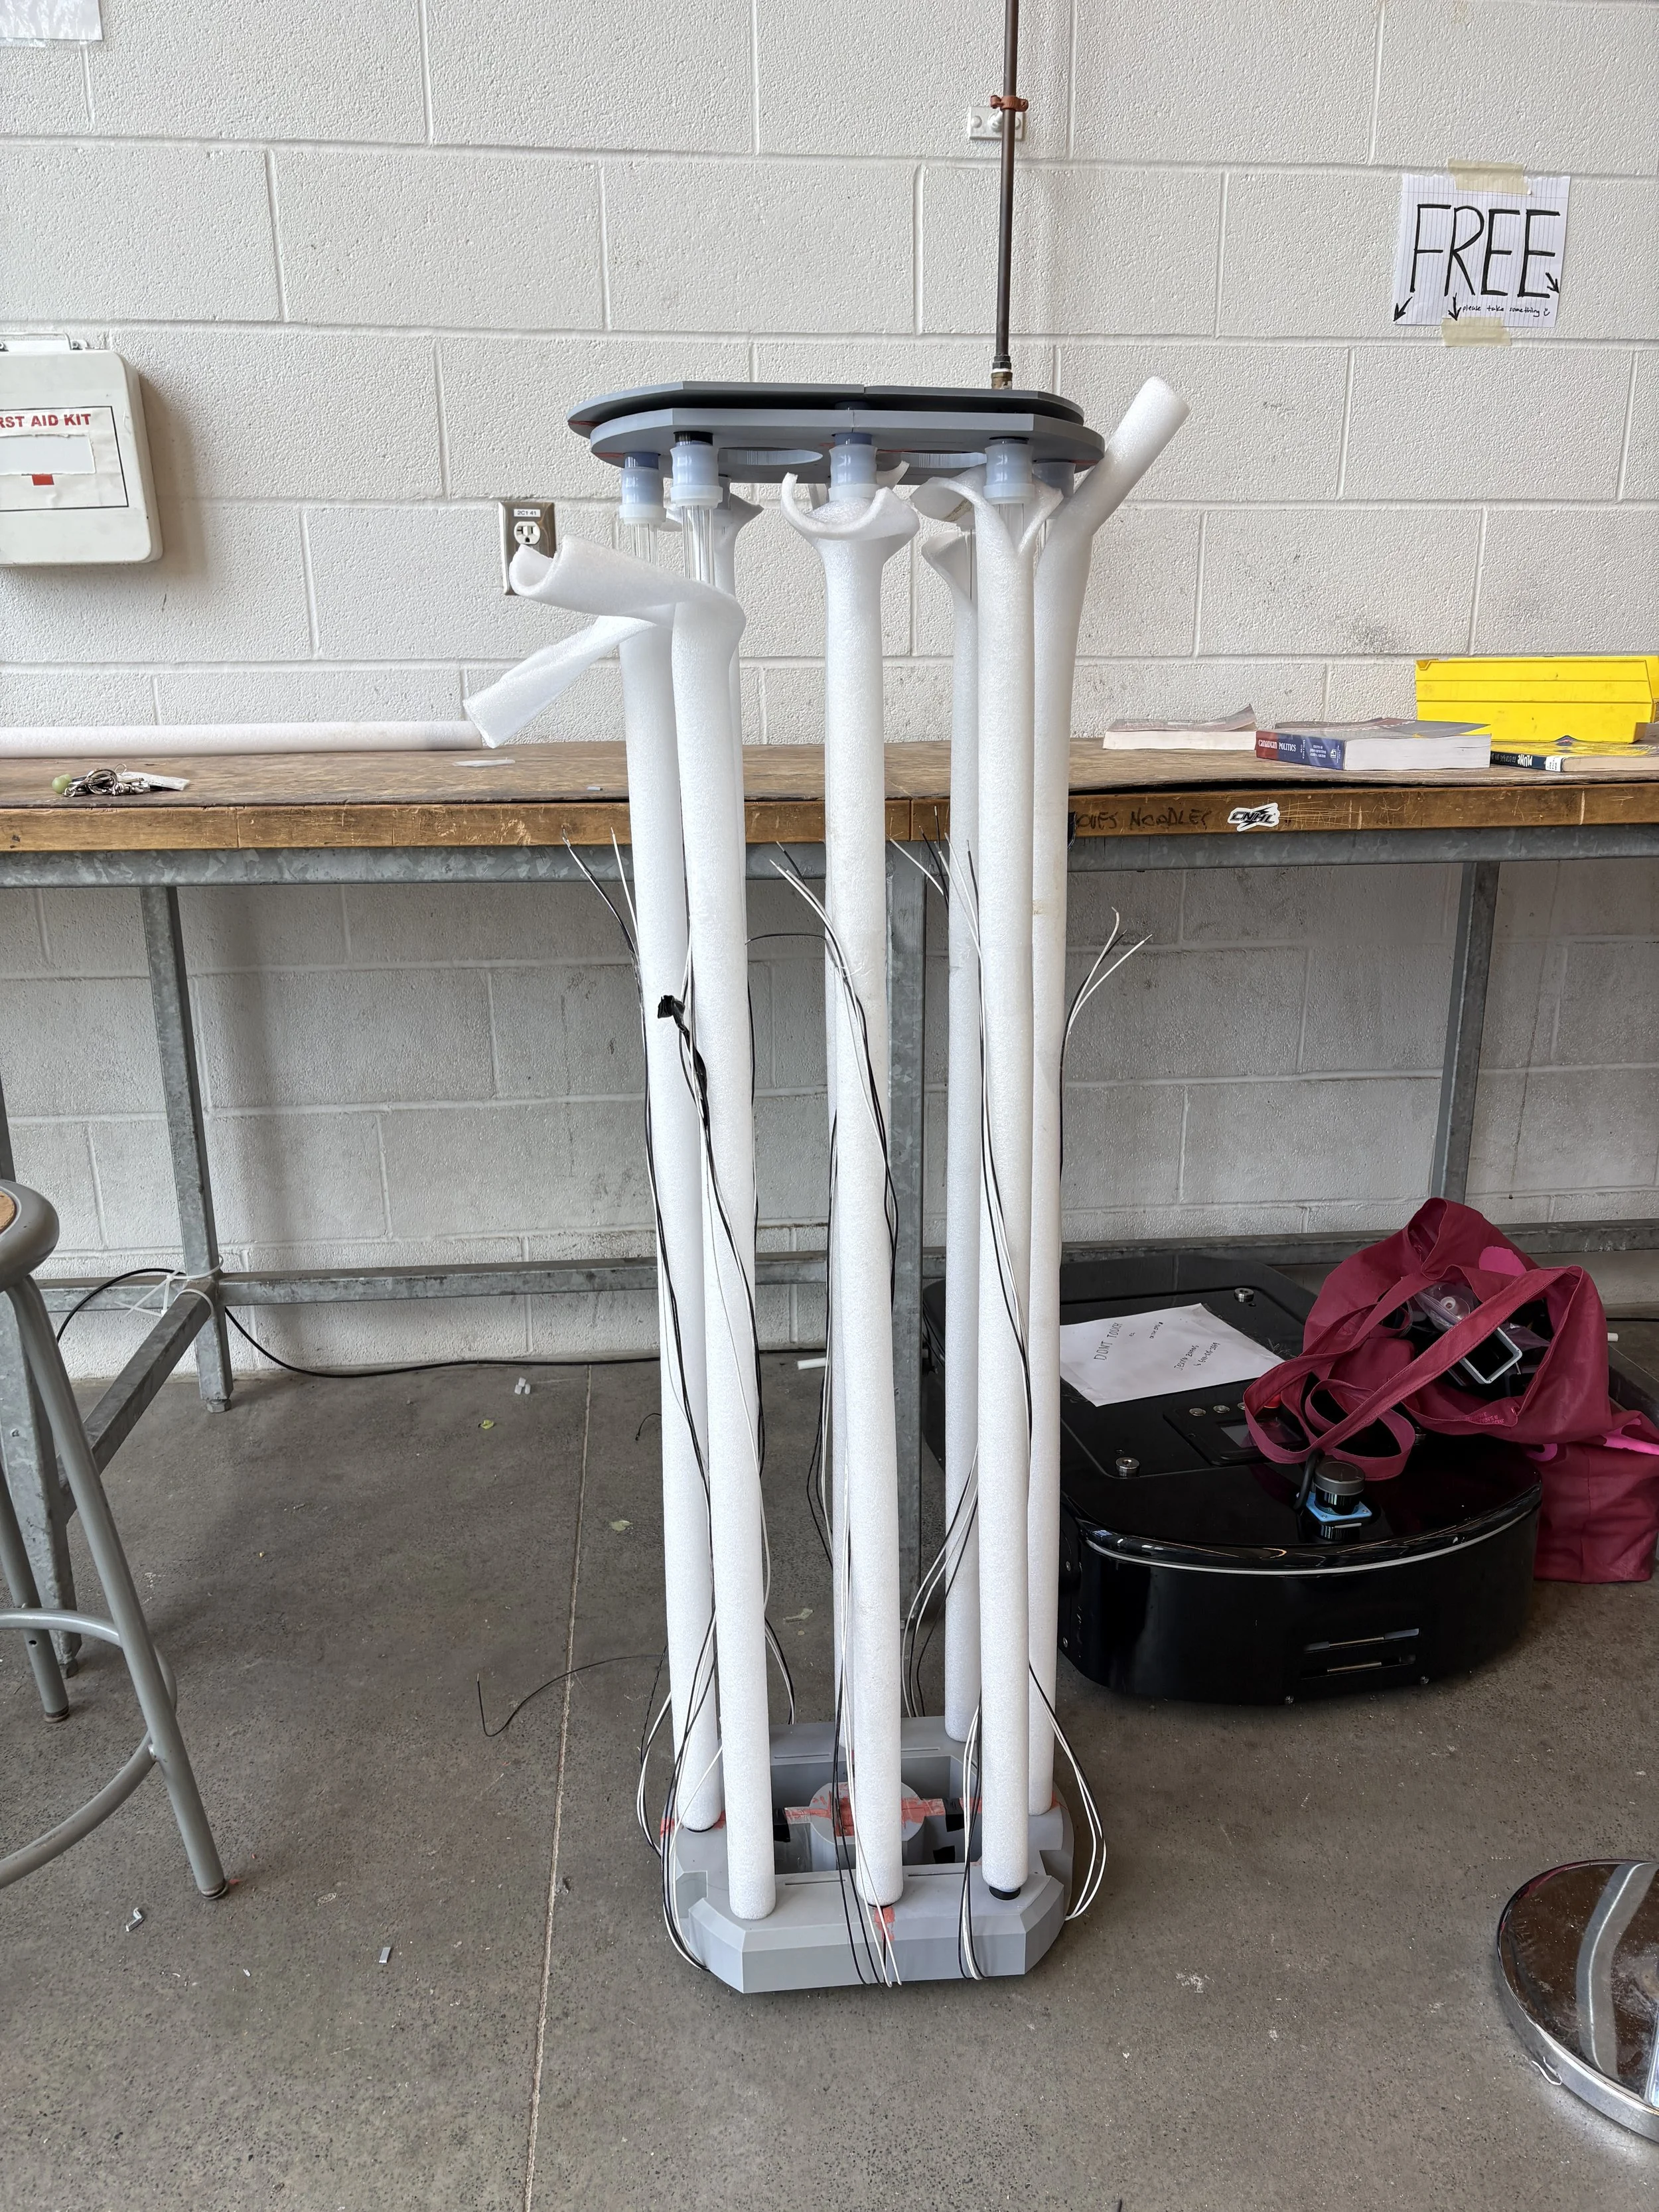
Assembling AMR for Prototype
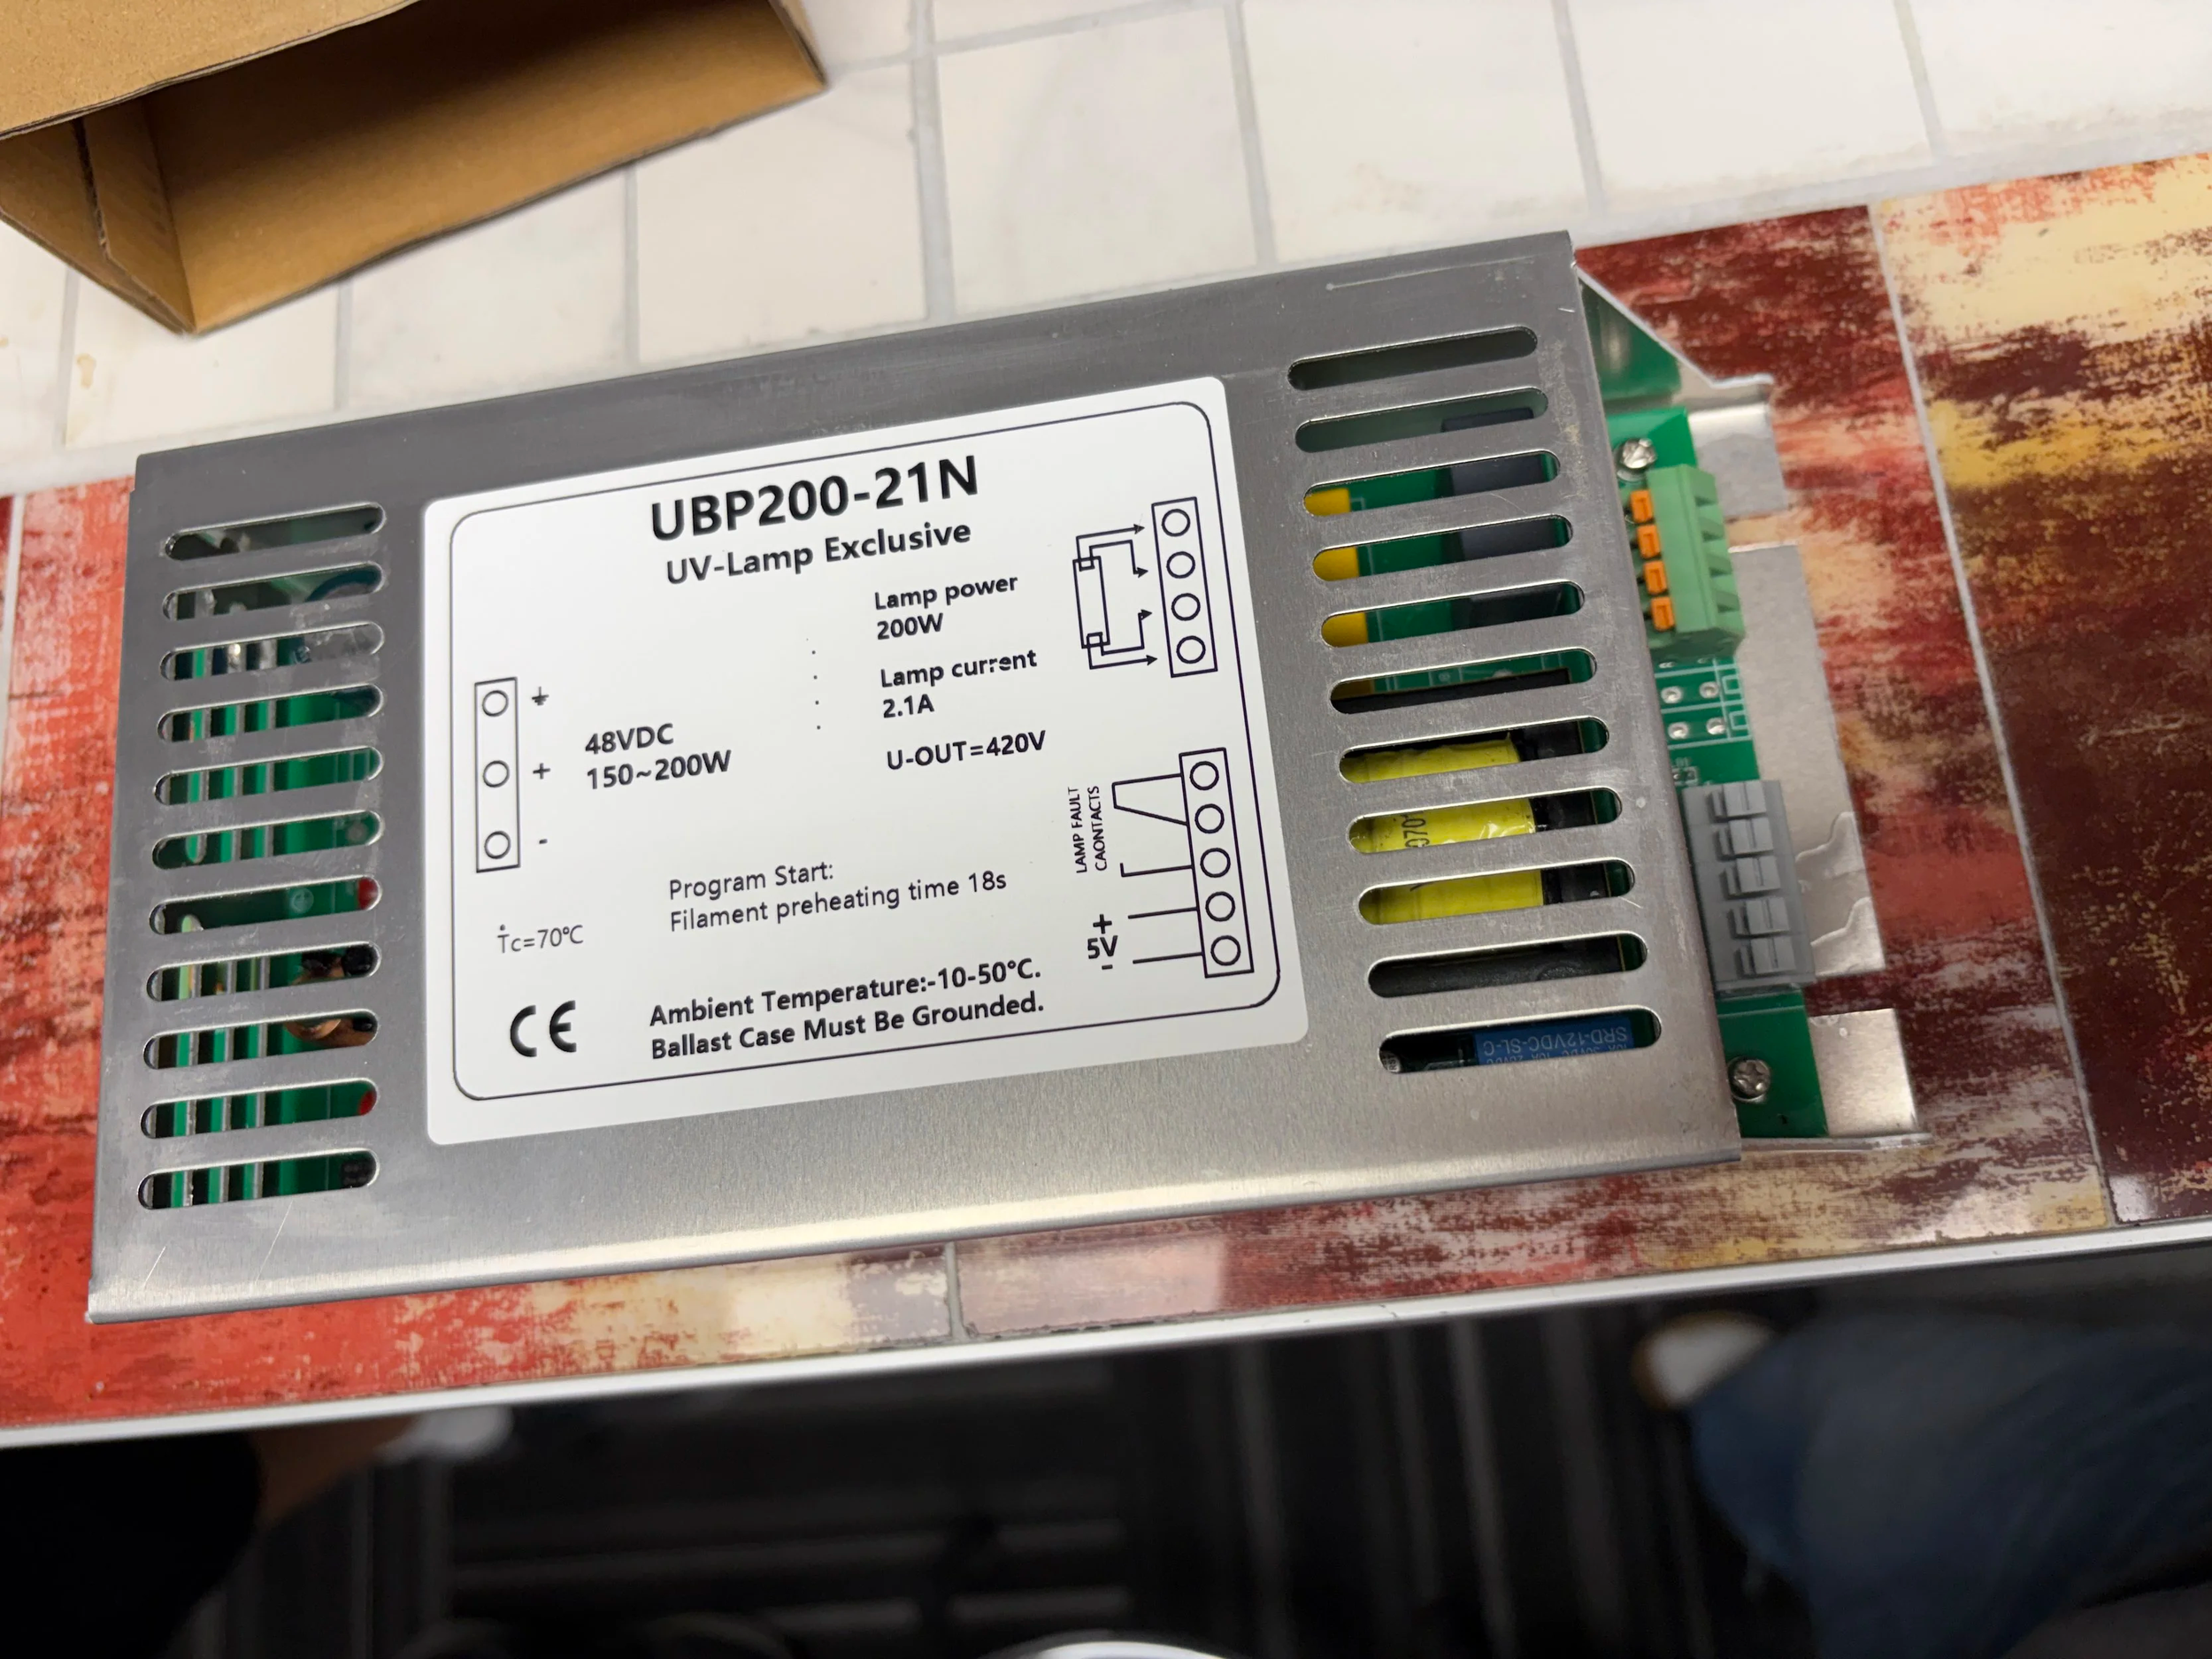
Sourced Ballasts
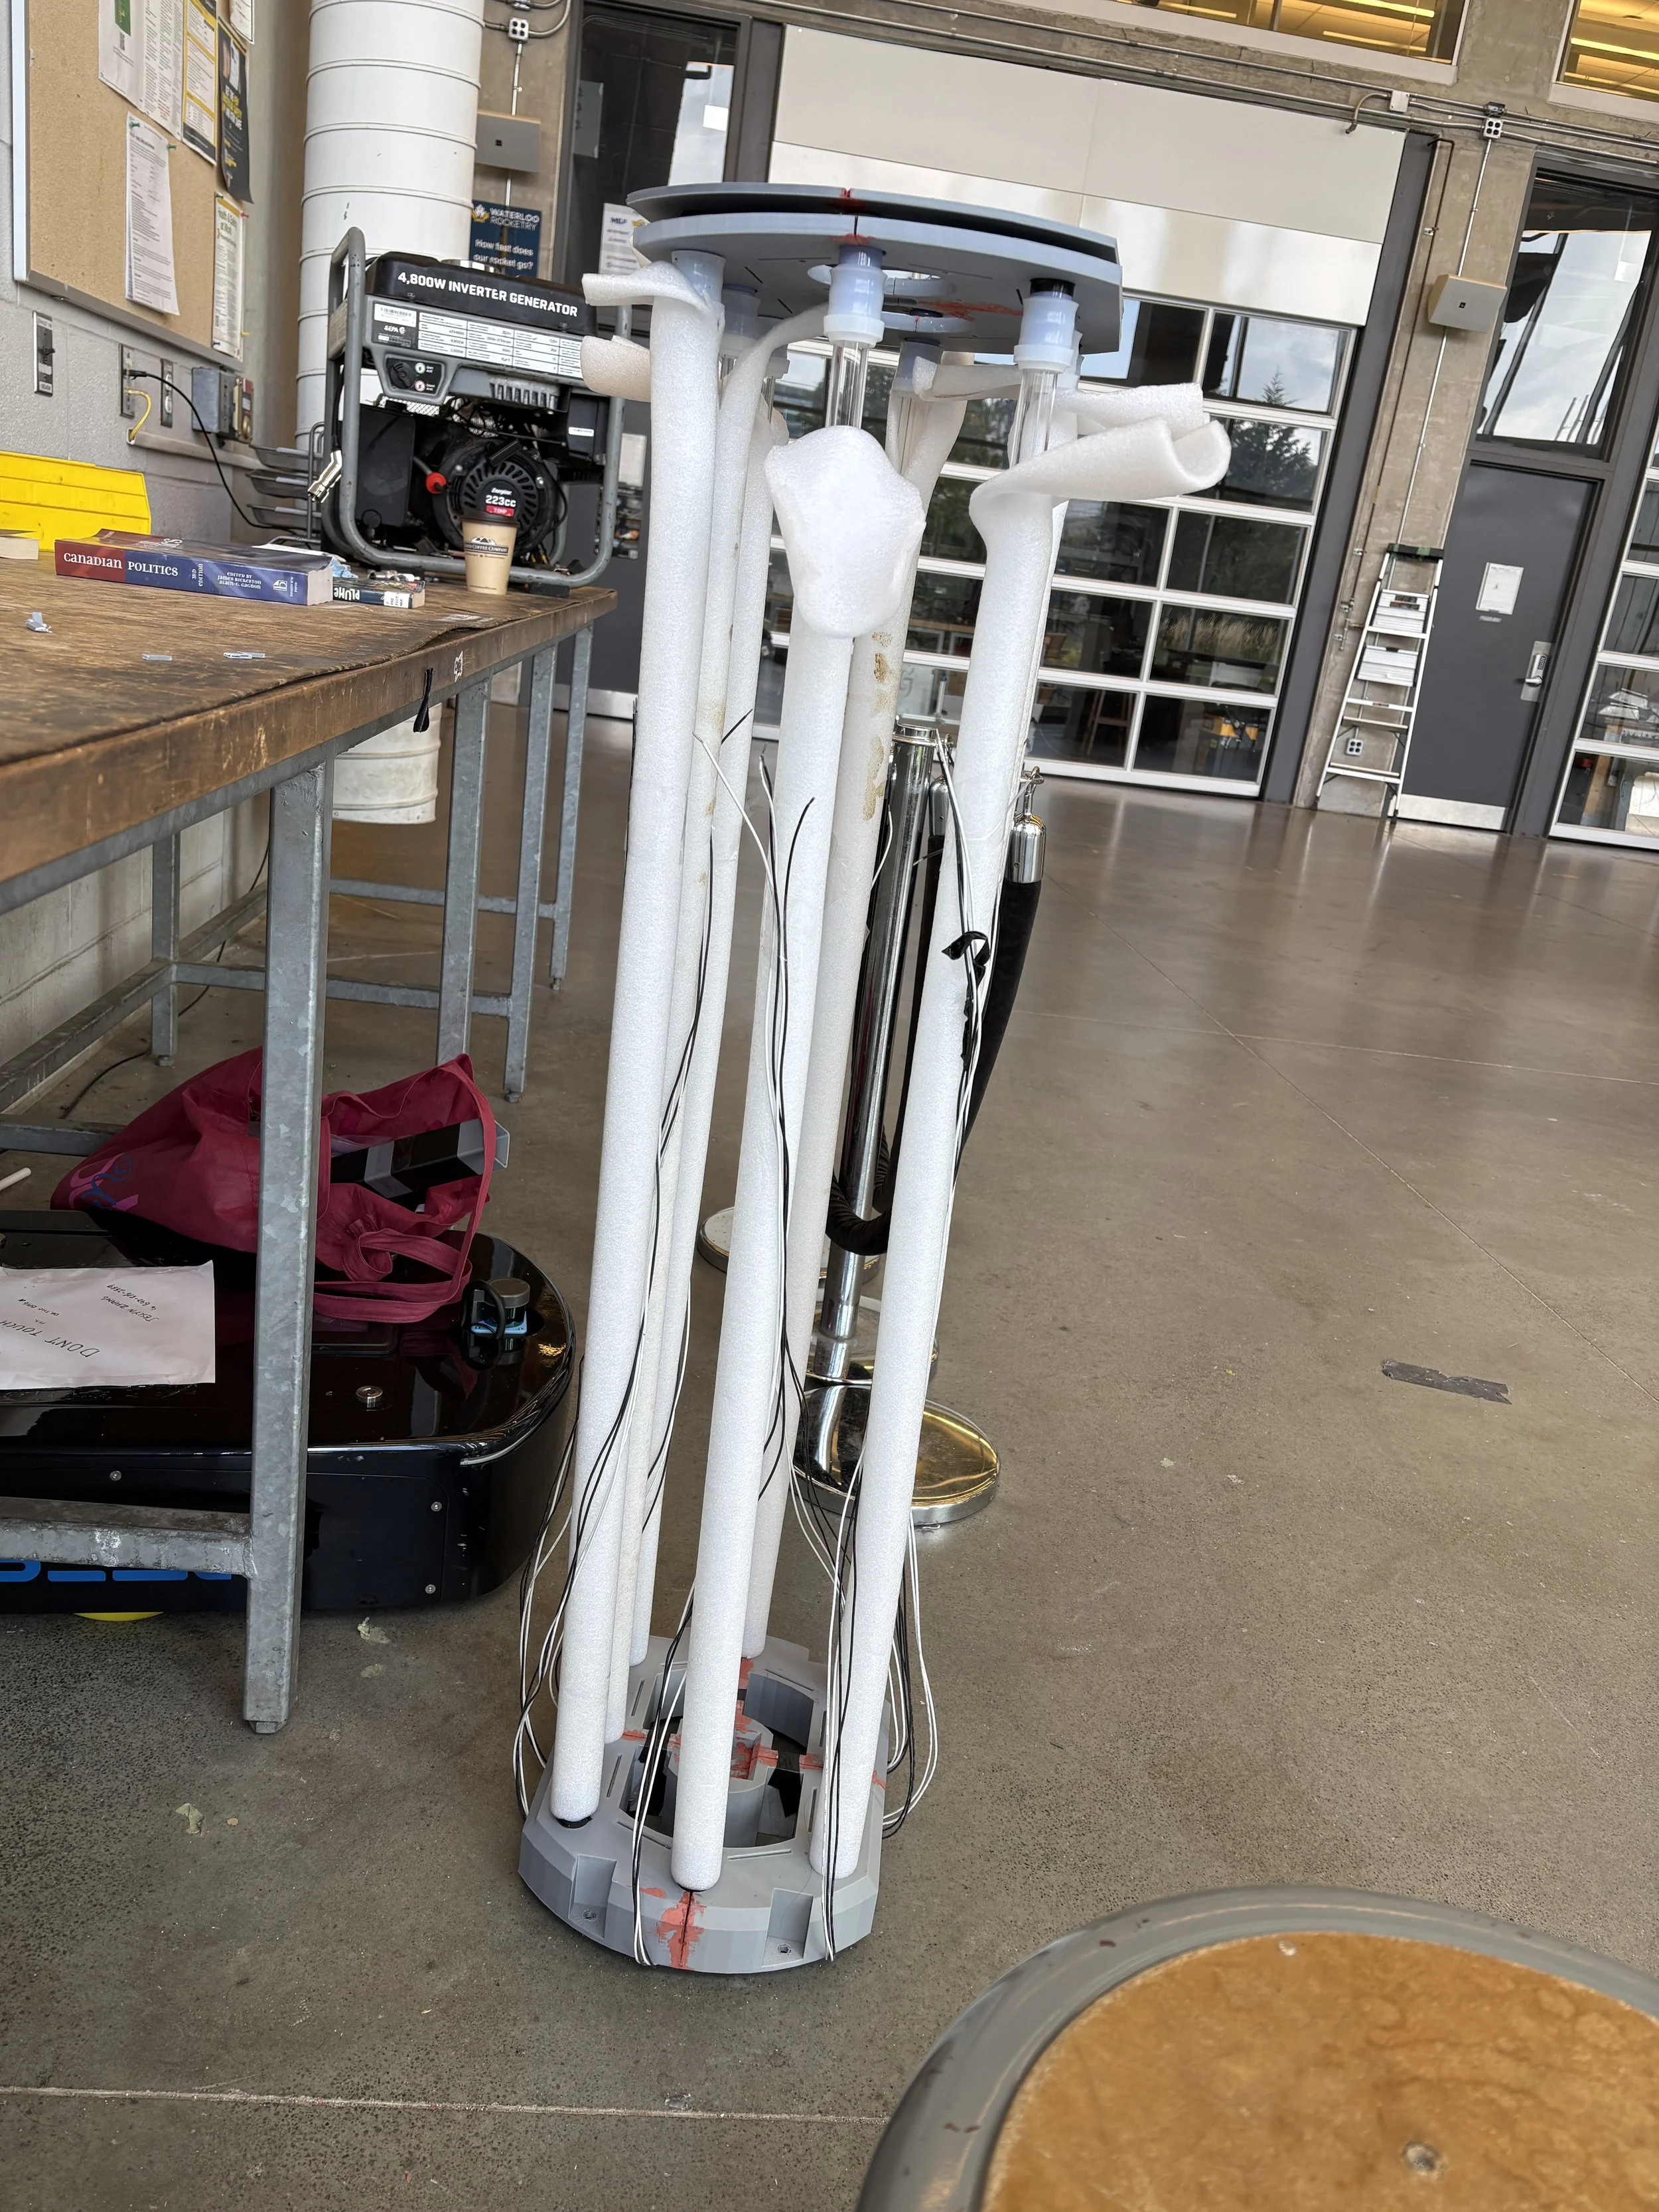
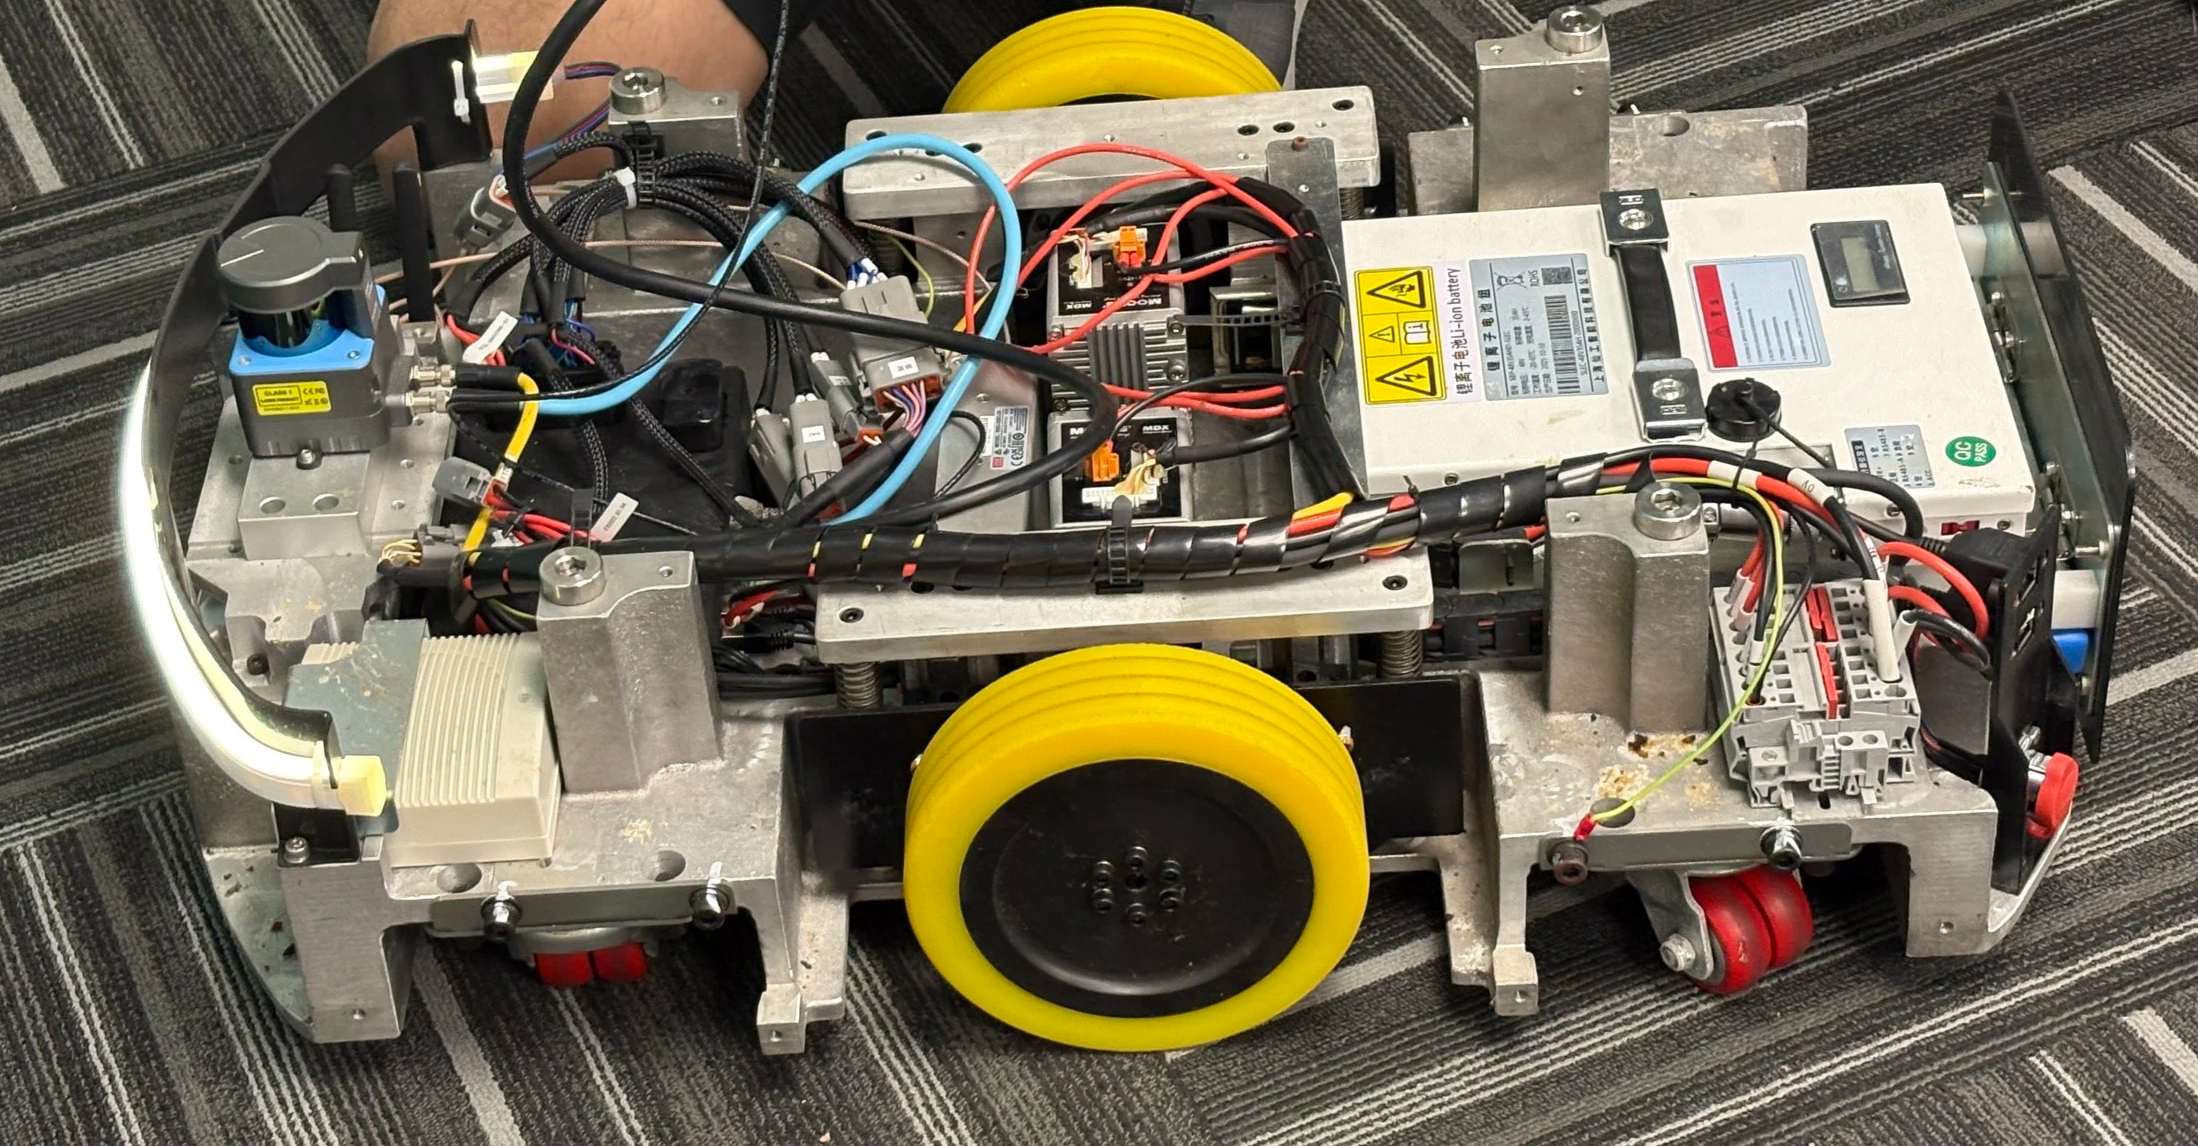
AMR without cover
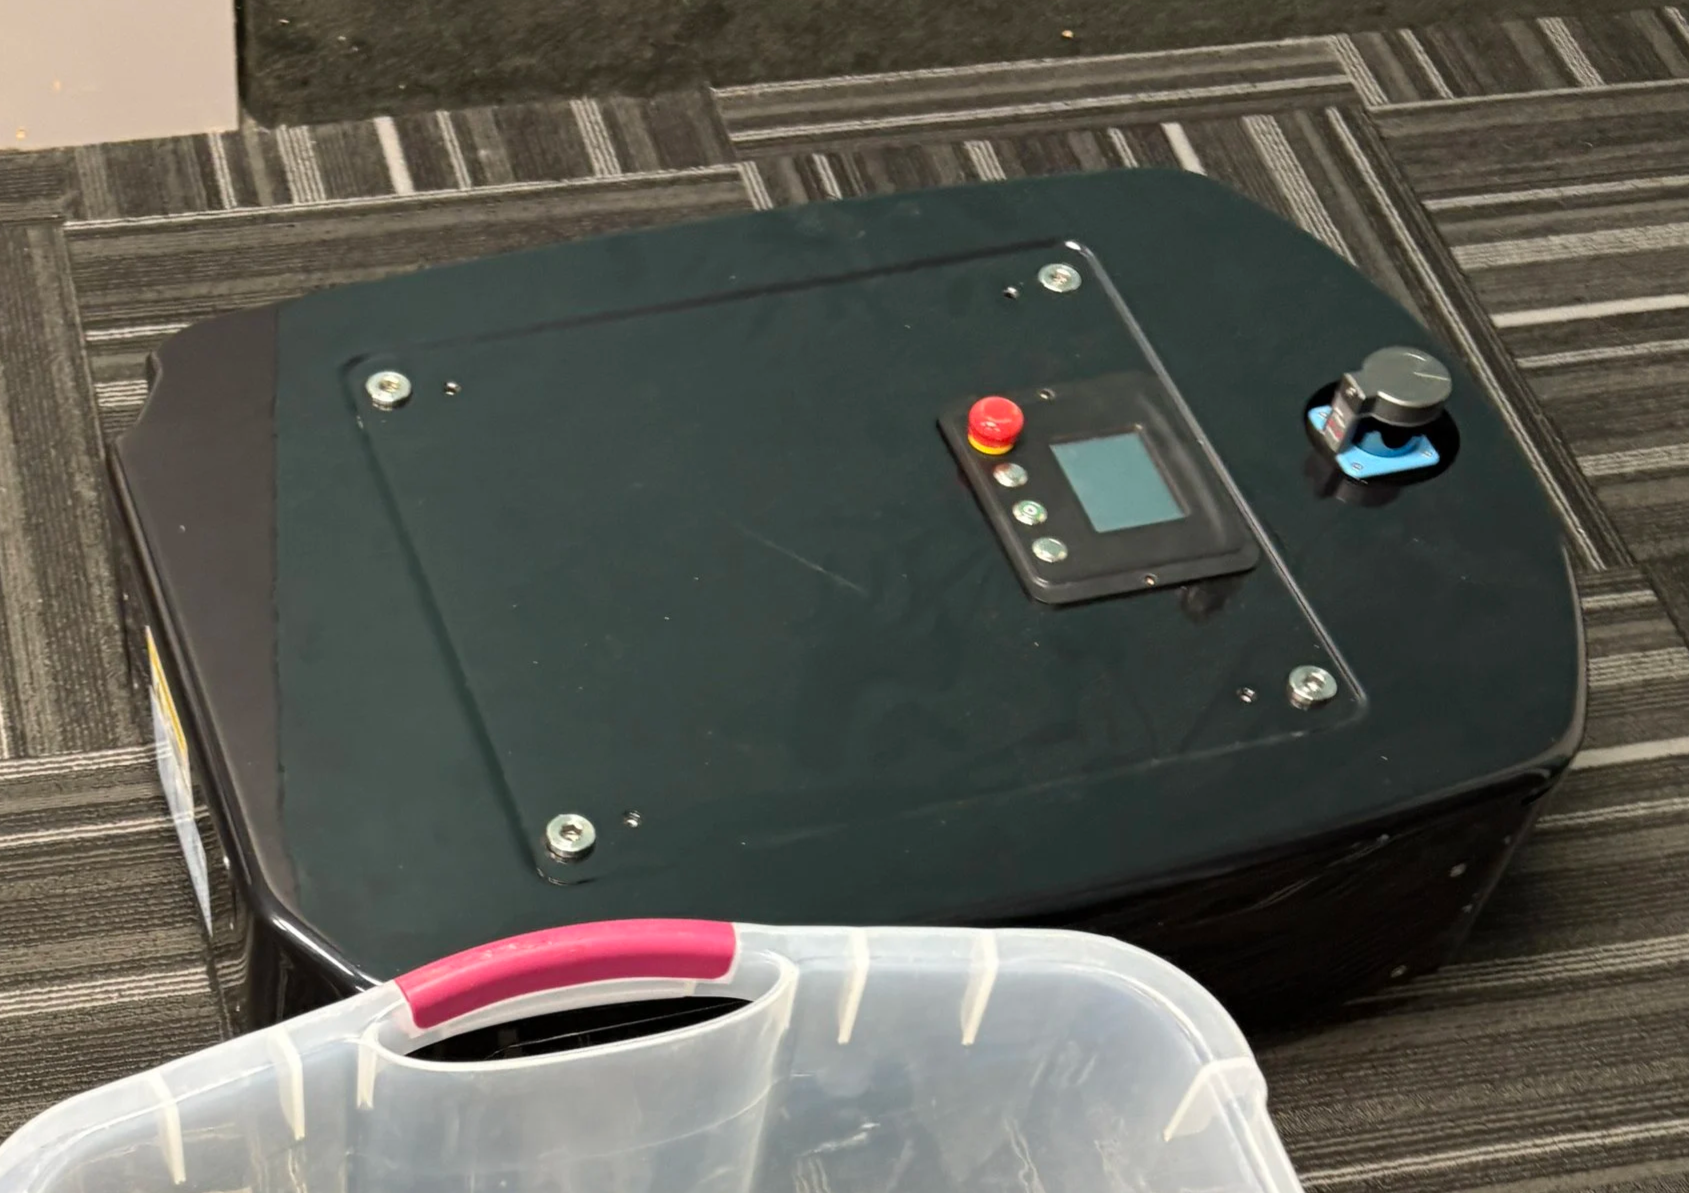
AMR with cover
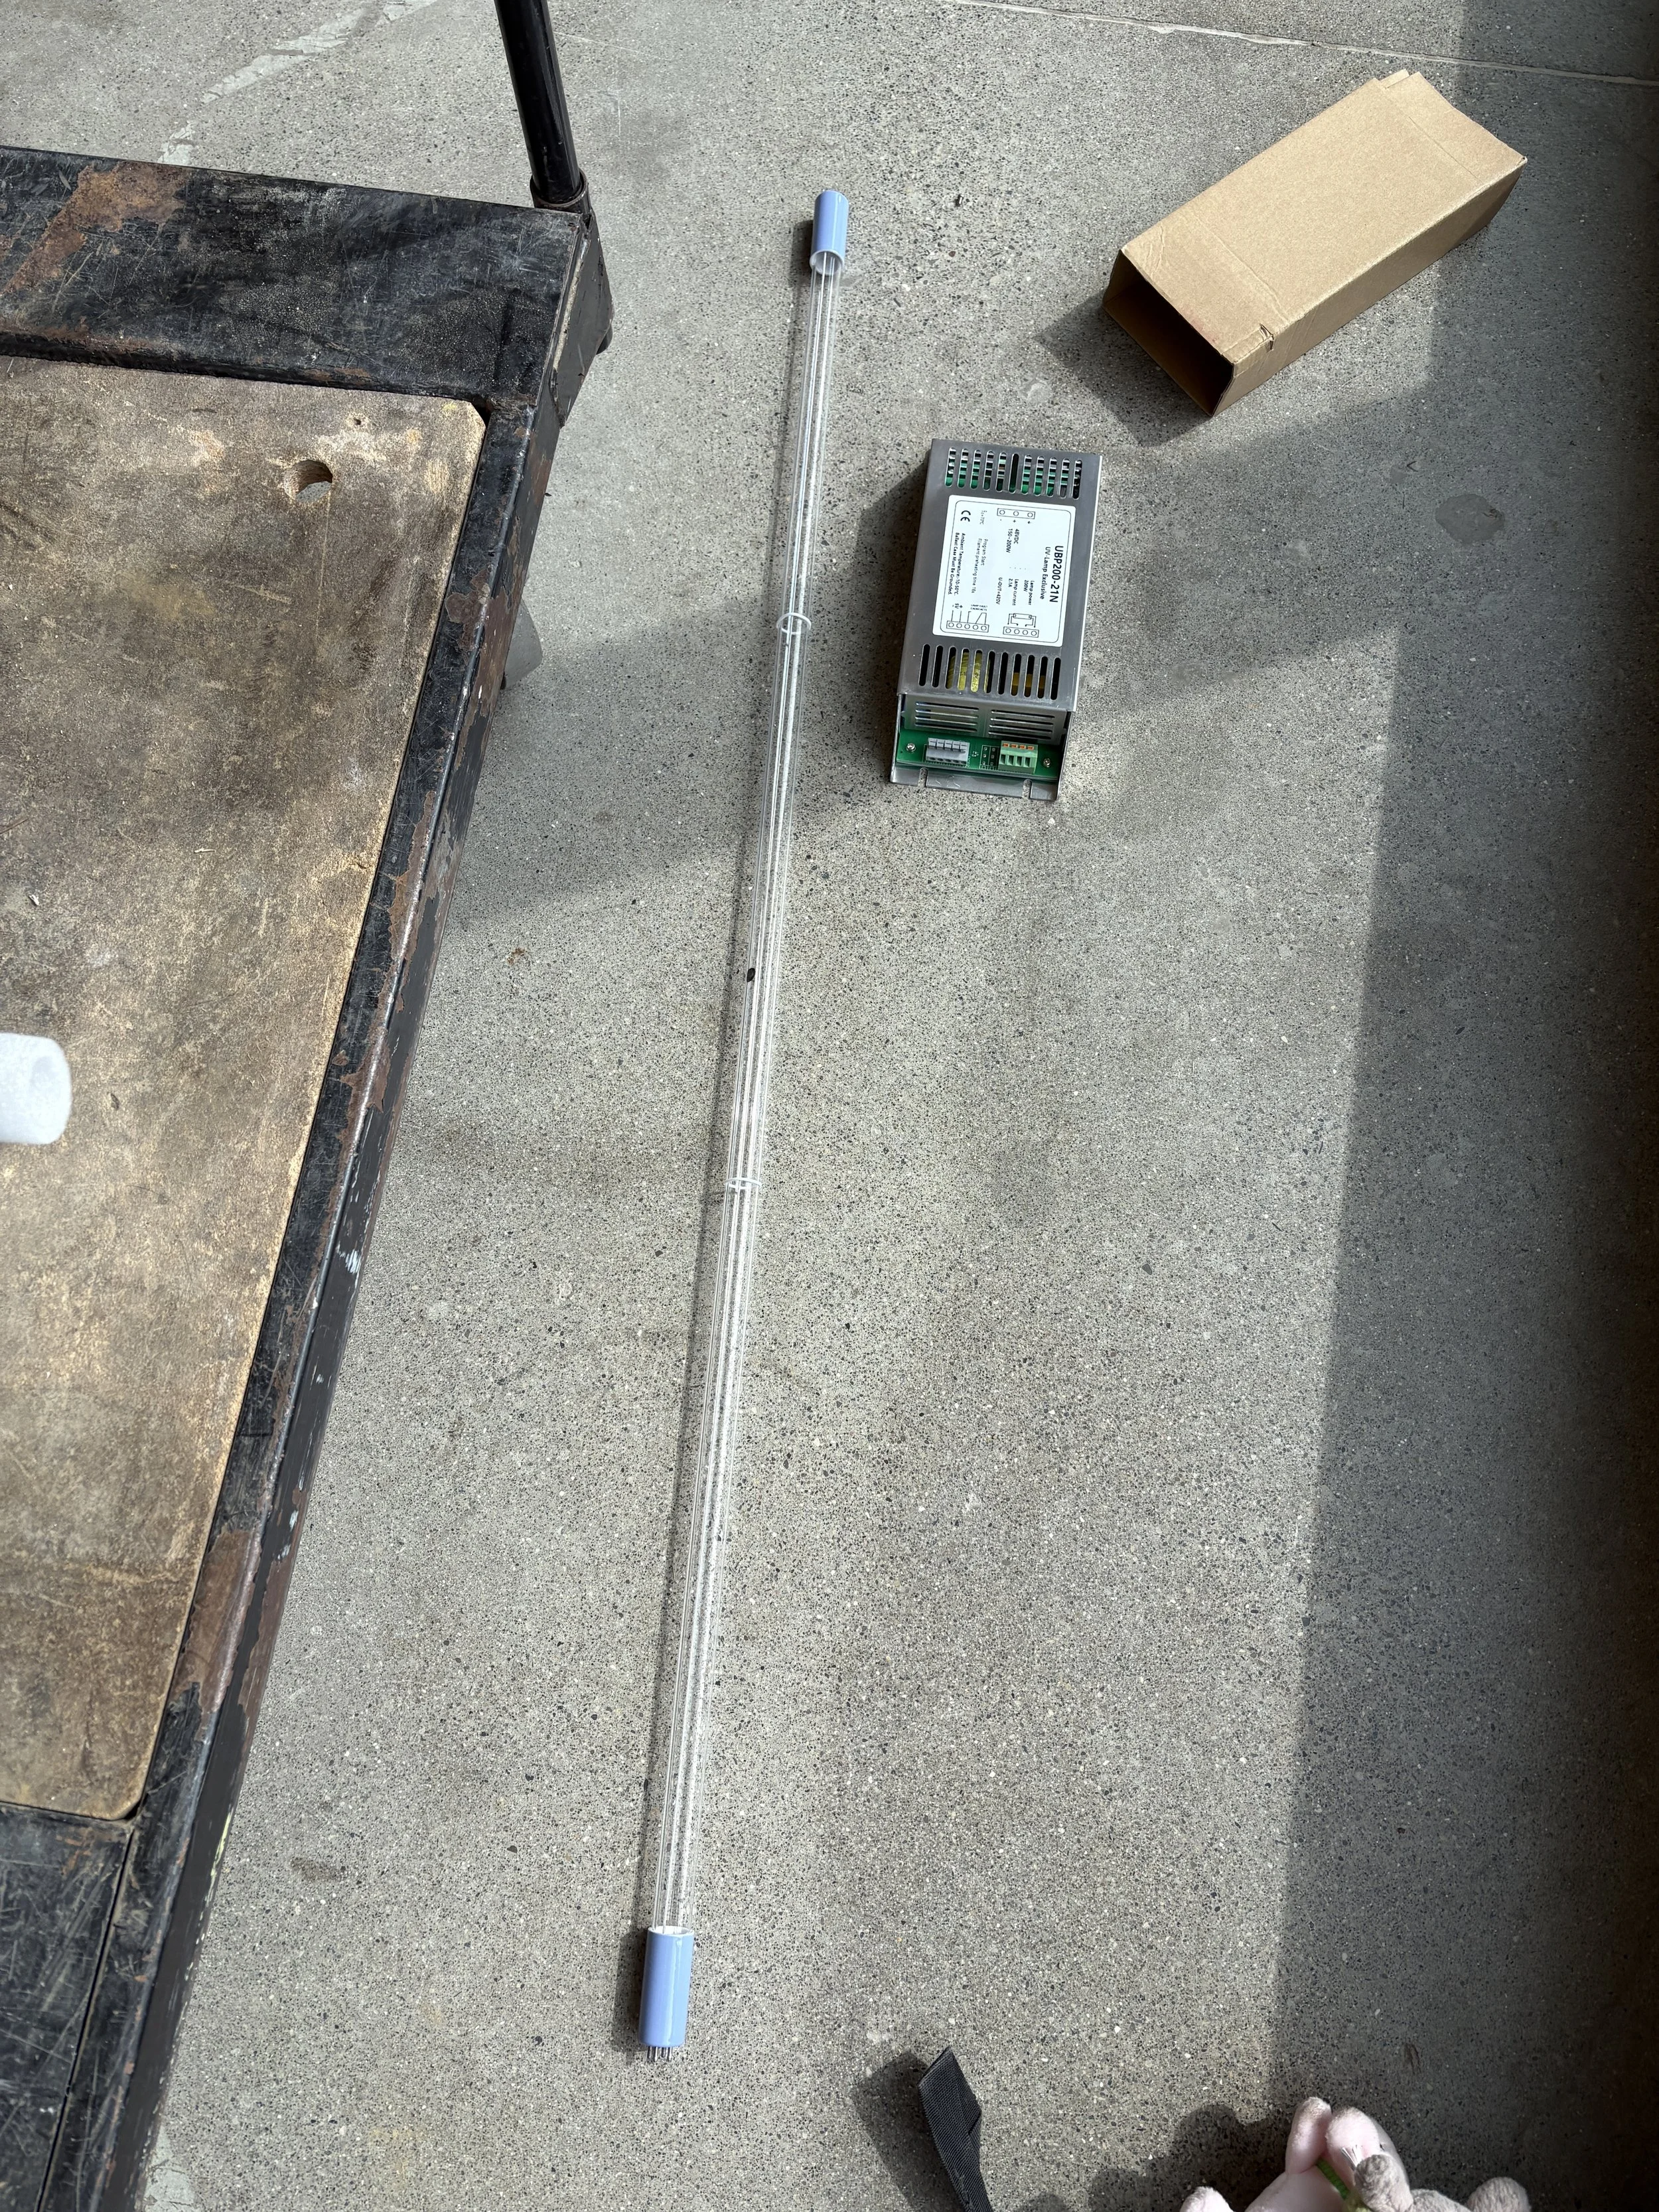
Some pictures of the CAD and prototyping process of the first version of the Agilbot.
Some Robot Testing Fun!
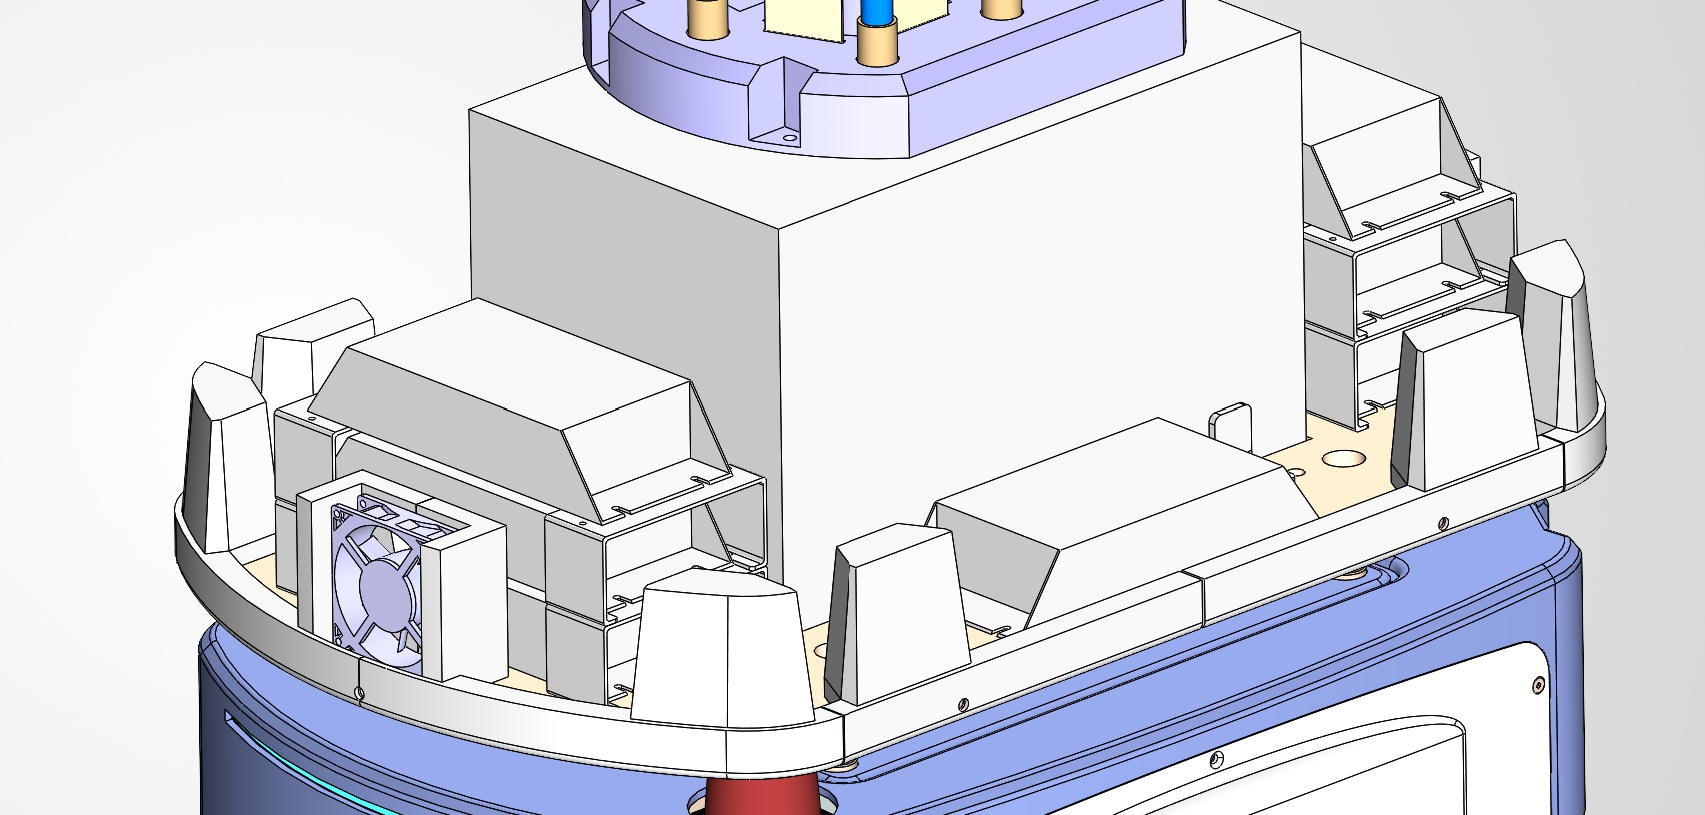
Internal Mounts
Full Prototype Test
Lamps were not turned on for the filming of the video (for my health)
Autonomous Navigating Testing